What does a median or trimmed-mean outer step cost local SGD, and what does it buy against Byzantine workers?
research/robust-outer
Median and trimmed-mean outer aggregation in local SGD: exact linear loop with floor and bias split, π/2 variance price with no attackers, bounded worst-case bias Φ(z)=1/(2(1−ε)) that more workers cannot average away but a longer inner loop shrinks.
What it found
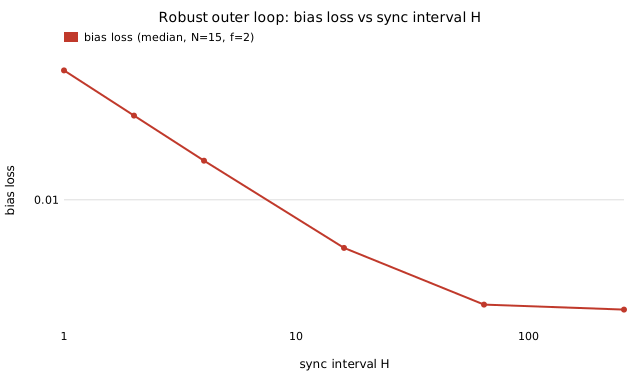
Because the median and trimmed mean commute with shifts, the outer loop stays exactly linear: floor αVwv/(s(2−αs)) plus a bias Vwm2/s2, with the same stability limit as averaging. With no attackers the median costs N·Var = 1.35 to 1.56 (→ π/2). With a fraction ε of attackers its bias is bounded (Φ(z) = 1/(2(1−ε)): 0.18 noise-sigmas at ε = 1/8) and beats averaging once the attack offset exceeds about 1.4 sigmas; more workers shrink only the variance part (total loss 0.103 → 0.102 from N=8 to 128), while a longer inner loop shrinks the bias (39× from H=1 to 256). Trimming exactly the attacker count is worse than the median. Matched to simulation within 1.3%. Stylised: quadratic, Gaussian noise, shared curvature, constant-offset attackers.
A figure from its own output
Paper, code and results
More in Decentralised training systems
- Which of sync interval, compression, delay, momentum and robust aggregation sets the final loss of low-communication training?Research programme (proposal stage): a predictive theory of DiLoCo-style low-communication training, testing on real small transformers the closed forms derived in about a dozen quadratic-model projects, with 16 references, hypotheses H1 to H6 and an ICML/NeurIPS workshop as the first target
- How far over its limit can a rate limiter be pushed in a true rolling window?How far over its limit can a rate limiter be pushed in a true rolling window? Adversarial search over fixed window, sliding log, sliding-window counter, token bucket and leaky bucket: only the sliding log holds the limit; the sliding counter admits up to about 1.5 L and the buckets nearly 2 L, and under Poisson overload at 1.5x load 39-47% of rolling windows exceed the limit for fixed window and buckets. Stylised.
- What can one stubborn node do to gossip training?Pairwise gossip for decentralised training: exact contraction
(n−2)/(2(n−1))≈½per matching round (~20 rounds at any n), noise floor(n−1)(n−2)s²/n, one stubborn node captures consensus at rate1−1/(n(n−1)), trust-region clipping caps drift atτ/(n(n−1))per step. - What does infrequent averaging do to the answer?Local-SGD/DiLoCo-style averaging on heterogeneous quadratics: exact fixed point with saturating weights
1-(1-ηa_i)^H, non-monotone bias to the unweighted mean, exacta_i/w_icorrection, step-count inflation moves the fixed point 0.50→0.91, wall-clock-optimal sync interval. - How often should preemptible workers checkpoint?Checkpoint interval for preemptible decentralised training: exact Lambert-W optimum independent of restart cost, Young/Daly overshoot 5–25%, flat within 2×, synchronous efficiency wall (50% at n≈691), flaky workers cut throughput 5×.
- Should a pipeline replicate stages or skip them?Replicate or skip? pipeline stages on unreliable workers: exact binomial drop law, replicas cannot beat the shared-domain floor
(1−ρ)^L, a 4-stage skip budget halves workers for a 1e-3 drop rate (240 → 96), cost-optimal design shifts from skipping to replication as skips get costly.
All 23 Decentralised training systems projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.