How big should a random verifier committee be?
research/committee-sampling
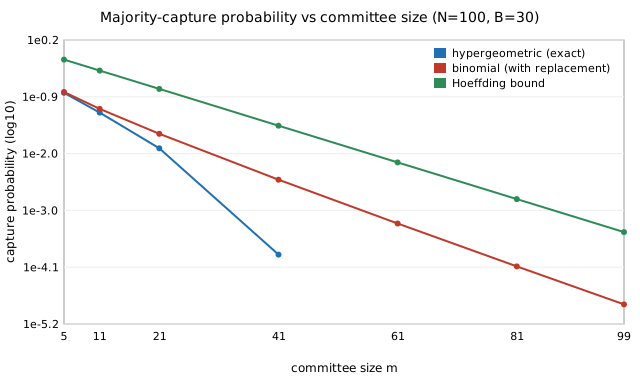
Verifier committees from a finite pool: exact hypergeometric capture (zero once m ≥ 2B+1, up to 26× below binomial), exact size ≈0.90 of ln(1/ε)/KL(½‖β) vs Hoeffding up to 2.2× too large, stake-weighted draws depend only on Byzantine stake share (20 of 100 nodes at 4× stake capture a 41-committee w.p. ½), and the threshold safety/liveness trade-off.
What it found
Drawing m verifiers from a pool of N with B Byzantine, majority capture is exactly hypergeometric: zero once m ≥ 2B+1 and up to 26× below the with-replacement binomial (N=100, B=30, m=41: 1.4×10⁻⁴ vs 3.6×10⁻³). For failure 2−40 the exact size is a steady ≈0.90 of ln(1/ε)/KL(½‖β) while Hoeffding over-sizes it up to 2.2×. With stake-weighted draws only the Byzantine stake share counts: 20 of 100 nodes at 4× stake capture a 41-member committee half the time. A threshold-t rule trades wrong acceptance (2.7×10⁻⁷ to 1.1×10⁻¹⁶) against stalls (2.7×10⁻⁷ to 3.3×10⁻²). Static adversary, exact computation.
A figure from its own output
Paper, code and results
More in Verification games & slashing
- Are reward pools identity-proof?Identity splitting vs merging under stake-weighted pools: split-invariant iff the weight is linear in stake, per-head optimum
√(Rn/c)−n, sharp deterrence feeRn/((n+1)(n+2)), wagering split-neutral. - Can a bond tell reliable hardware from unreliable?Can a bond tell reliable hardware from unreliable? Single crossing runs the wrong way: reliable rent
(θ_H−θ_L)(c+(1+ρ)s_H)/(1−θ_H)is minimised at zero stake, a flat wage is optimal, and a deterrence stake scales rent by(c+(1+ρ)s)/c. - How many milestones does an unenforced job need?Milestone payments without enforcement: a split pre-payment needs only the pooled relationship value (
C/(W_r+W_w)vsP/W_r,C/W_w), and front-loading makes the milestone count logarithmic,⌈ln(1+(V−C)/W)/ln(V/C)⌉(17 vs 100 at W=1). - What is the cheapest payment-and-audit protocol that makes honest ML training an equilibrium?Research programme: incentive-compatible verification of outsourced ML training; first measurement on real training finds a tolerance-tau referee passes a skip-steps cheat on 30% of steps at tau = 1e-2 while the held-out loss stays within one seed std, and the loss only suffers at tau about 10x the worst benign drift; milestone 4 prices contracts by linear programme: with a tolerance, audit-only cannot enforce full effort and the joint contract beats both checks only when the score is precise (4 of 45 cells); milestone 6: against a coordinating majority replication adds no deterrence beyond the audit and the stake is flat in the number of workers (140 cells); milestone 5: an agreement term between redundant workers is worth nothing beyond the audit once cheats copy one trajectory (0 of 1,349 random instances), and a proved one-sided bound max(C, g/p - S) holds in 2,755 instances but is vacuous for a noisy score
- Economics of refereed verificationInspection-game economics of refereed verification: stake substitutes for re-execution, extra verifiers free-ride, and optimal tolerance/stake under floating-point drift.
- Bribing the verifiersBribing verifiers in refereed verification: closed-form bribe floor, a sharp collusion-proof stake that falls as 1/m, and jackpots that raise the floor one-for-one.
All 19 Verification games & slashing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.