Does the ranking of printable soft-fruit gripper designs survive a shift in friction, fruit, placement error and print tolerance?
research/codesign-transfer
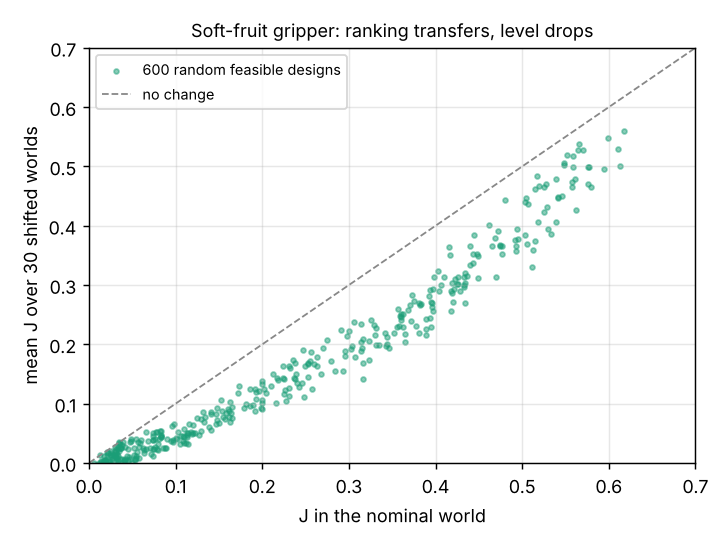
Does the ranking of soft-fruit gripper designs survive a shift in friction, fruit, placement error and print tolerance? Yes in this model (Spearman 0.993 over 600 designs), but the nominal optimum loses 13% of its J and a robust optimum gains only about 0.015 on average; sim-to-sim, assumed ranges.
What it found
Takes the codesign-agri contact model unchanged and widens what it holds fixed: per world the fruit size, placement error, wetness, bruise threshold and stem pull are drawn, and the printed gripper differs from the design (pad modulus, force and width tolerance). Over 600 random feasible designs and 30 held-out worlds the Spearman rank correlation with the nominal world is 0.993, so a nominal winner is a good candidate. The level still falls: the nominal CMA-ES optimum loses 13% of its objective (0.653 to 0.567), and a robust optimum trained on 10 other worlds gains only 0.015 on average and 0.034 in the worst world, from single runs. Sim-to-sim in a stylised model with assumed ranges; no gripper was printed.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Which grasp scenes can no printable two-finger gripper hold, and what limits the ceiling?Which grasp scenes can no printable two-finger gripper hold? 10 of 140 (7%), all spheres with the hand more than about 2 mm above their centre height; lowering only the hand holds all 10, so the 0.85 plateau in
codesign-diagnoseis scene geometry, not friction or force (stylised, found after the fact, one intervention). - Does diagnostic feedback (a failure summary, full rollout logs) help a design loop find better printable grippers than the score alone?Does a failure summary or full rollout logs help a gripper design loop beyond the score alone? No: three scripted readers end at 0.84 to 0.86 best test success, like random search, CMA-ES and Bayesian optimisation (stylised, rule-based readers, not an LLM).
- How much of a best-of-40 gripper design's score is selection noise when every design gets its own trained grasp force?Do agent-proposed gripper fingers beat random search, CMA-ES and Bayesian optimisation when each design gets its own trained grasp force? On 40 held-out scenes all methods' best seeds reach 0.93 to 0.95 and the ranking is within noise; on 100 fresh scenes the session agent's 0.95 falls to 0.81, level with the baseline median (stylised, preliminary, mostly negative).
- Does tilting a quadrotor's rotors buy the yaw authority that no attitude controller could?Does a rotor cant angle, co-designed with arm length and propeller size, beat the yaw limit that control-law changes could not move? In simulation yes: joint co-design with free cant (chosen at the 35° bound in 5 of 5 seeds) cuts held-out attitude error from 15.22° to 12.32°, at equal evaluations.
- Where is the best rotor cant angle for a quadrotor co-designed with its controller?Does more rotor tilt keep helping once the 35° cap of codesign-aero-cant is lifted? In simulation no: with the bound at 35°, 50°, 65° and 80° the joint co-design reaches 12.3° held-out attitude error and picks 34–40° each time, so the optimum is interior and flat; an assumed tilt efficiency loss changes it by 0.1°.
- Does the best rotor cant angle change when yaw reaction torque scales with propeller size?Does the interior cant optimum survive a reaction torque that grows with propeller diameter (κ = c·D) instead of a fixed 0.016 m? In simulation yes: for c = 0.06, 0.126 and 0.25 the joint co-design reaches 12.5°, 12.3° and 11.8° held-out attitude error with the bound at 80°, picks 33–41° each time, and cant still beats no cant in 5 of 5 seeds; the gain is largest (−4.8°) for the weakest reaction torque.
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.