Which suction gripper picks the most of a stylised mixed tote under an 80 USD cap, and does a session agent beat CMA-ES and Bayesian optimisation?
research/codesign-logistics
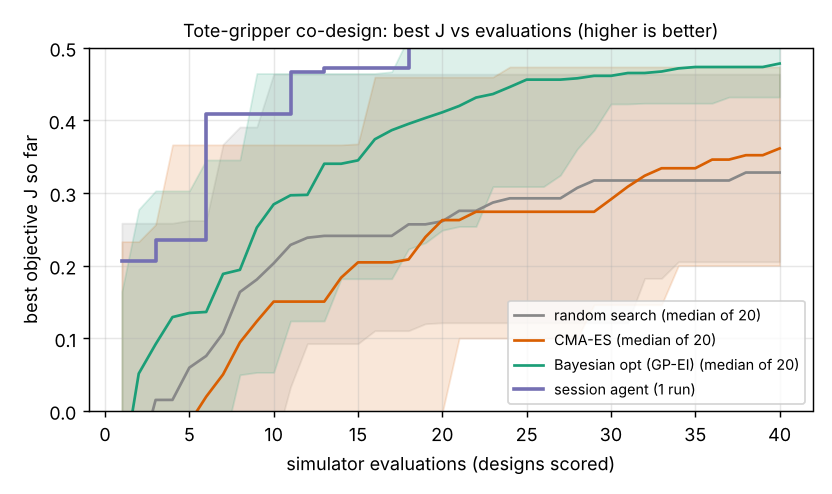
Which suction gripper picks the most of a stylised mixed tote (boxes, polybags, bottles) under an 80 USD cap, and can an agent beat CMA-ES and Bayesian optimisation at 40 evaluations? The agent's best J was 0.519 against 0.478 for Bayesian optimisation (median of 20 seeds); the best design is two 18.5 mm cups at 80 kPa and 60 L/min, and a catalogue-default single 30 mm cup scores 0.075. Stylised, assumed constants.
What it found
Five design variables (cup diameter, cups in a row, pump vacuum, pump flow, cup compliance) are scored on 600 simulated items (boxes, leaky polybags, bottles) with a cup-fit law on each item’s flat patch, vacuum lost to leaks, holding force against 1.5× a 1 g-accelerated load, and a pick-time penalty. At 40 evaluations the median best objective is 0.478 for Bayesian optimisation, 0.361 for CMA-ES and 0.328 for random search; a session agent’s hand-written proposals (one run, by the model’s own author) reached 0.519, and 1 of 20 Bayesian-optimisation seeds matched it. The best design (two 18.5 mm cups, 80 kPa, 60 L/min) holds 77% of items quickly; a catalogue-default single 30 mm cup holds none quickly (J 0.075). Stylised, with assumed constants, no learned policy and no general-purpose arm modelled.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Should a quadrotor’s airframe and its learned attitude controller be sized together, or one after the other?Should a quadrotor's airframe and its learned roll controller be sized together? Yes in this stylised model: joint CMA-ES reaches 5.25° RMS roll error, equal to the grid optimum, against 7.06° for lightest-airframe-first; a controller reused across airframes is worse on 41% of them.
- Does the best quadrotor airframe stay best when motor strength, mass and motor lag are randomised?Does the best quadrotor airframe stay best under widened motor-strength, mass and lag randomisation? Mostly: top five unchanged (Spearman 0.75), but retuning gains helps the median airframe 0.91° (stylised).
- Should a quadrotor’s airframe and controller gains be searched jointly when the plant is uncertain?Should airframe and gains be searched jointly under an uncertain plant? Yes in this stylised model: joint CMA-ES at 960 evaluations (5.75° median held-out, 8 seeds) beats random search and a 4800-evaluation grid-then-tune best cell (6.00°).
- Is the quadrotor airframe ranking from one tuning run reproducible, or is it tuning noise?Is the airframe ranking from one tuning run reproducible? With wide-tuned gains yes (Spearman 0.99 over six replicates); with nominal-tuned gains it is noisier (0.84) and the earlier 0.17° regret was within noise (stylised).
- Does the ranking of printable soft-fruit gripper designs survive a shift in friction, fruit, placement error and print tolerance?Does the ranking of soft-fruit gripper designs survive a shift in friction, fruit, placement error and print tolerance? Yes in this model (Spearman 0.993 over 600 designs), but the nominal optimum loses 13% of its J and a robust optimum gains only about 0.015 on average; sim-to-sim, assumed ranges.
- Which grasp scenes can no printable two-finger gripper hold, and what limits the ceiling?Which grasp scenes can no printable two-finger gripper hold? 10 of 140 (7%), all spheres with the hand more than about 2 mm above their centre height; lowering only the hand holds all 10, so the 0.85 plateau in
codesign-diagnoseis scene geometry, not friction or force (stylised, found after the fact, one intervention).
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.