Which printable two-finger gripper holds eight different objects for the least plastic, and can an agent beat CMA-ES and Bayesian optimisation at 40 simulations?
research/codesign-gripper
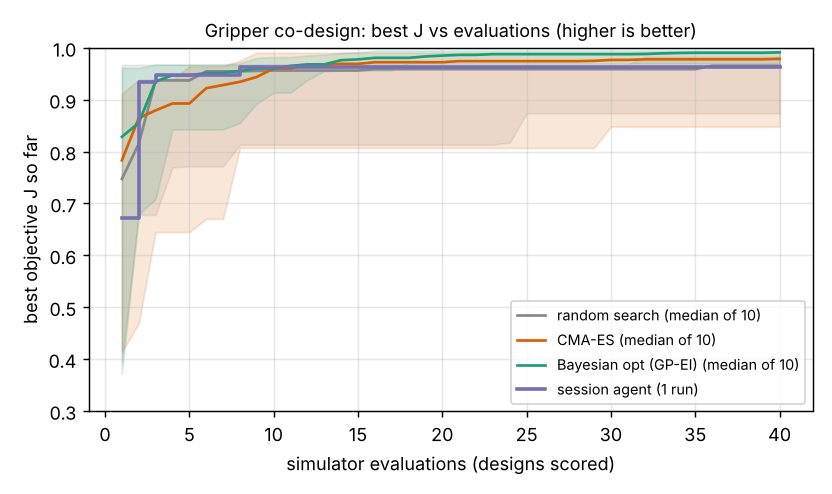
Which printable two-finger gripper holds eight objects for the least plastic, and can an agent beat CMA-ES and Bayesian optimisation at 40 MuJoCo evaluations? Median best objective 0.991 (Bayesian opt) vs 0.979 (CMA-ES), 0.965 (random) and 0.963 (session agent, one run); the cheapest winners (0.5 g flat fingers) are also the most fragile when object offsets triple. Stylised, no learned policy.
What it found
A parametric 3D-printable gripper finger (length, thickness, pad width, V angle) scored in MuJoCo on eight objects with a per-design grip force. At 40 evaluations the median best objective is 0.991 for Bayesian optimisation, 0.979 for CMA-ES, 0.965 for random search and 0.963 for a session agent’s hand-written proposals (one run; Bayesian optimisation matched or beat it in 10 of 10 seeds). The best designs are tiny flat fingers (0.5 g), but re-scored with object offsets tripled they hold 5 of 8 objects against 6 of 8 for the agent’s wide V. Rigid, stylised, no learned policy, nothing printed.
A figure from its own output
Paper, code and results
More in Agentic co-design of low-cost robots
- Which cheap wheel-legged rover covers the most stylised rubble under a 120 USD parts cap, and does a session agent beat CMA-ES and Bayesian optimisation?Which cheap wheel-legged rover covers the most stylised rubble under a 120 USD cap, and can an agent beat CMA-ES and Bayesian optimisation at 40 evaluations? Wheel radius at its bound plus about 0.5 N m torque reaches the ceiling (J 0.783, 69 USD); Bayesian opt and CMA-ES 0.782, session agent 0.783, random 0.716; stylised, falls never occurred.
- Which three-finger pad design picks the most unbruised strawberry-like fruit under a 60 USD cap, and does a session agent beat CMA-ES and Bayesian optimisation?Which three-finger pad design picks the most unbruised strawberry-like fruit under a 60 USD cap, and can an agent beat CMA-ES and Bayesian optimisation at 40 evaluations? Bayesian optimisation did (median J 0.635 against the agent's 0.618); about 20% of fruit are lost to clutter collisions no pad setting changes. Stylised, assumed constants.
- Which suction gripper picks the most of a stylised mixed tote under an 80 USD cap, and does a session agent beat CMA-ES and Bayesian optimisation?Which suction gripper picks the most of a stylised mixed tote (boxes, polybags, bottles) under an 80 USD cap, and can an agent beat CMA-ES and Bayesian optimisation at 40 evaluations? The agent's best J was 0.519 against 0.478 for Bayesian optimisation (median of 20 seeds); the best design is two 18.5 mm cups at 80 kPa and 60 L/min, and a catalogue-default single 30 mm cup scores 0.075. Stylised, assumed constants.
- Should a quadrotor’s airframe and its learned attitude controller be sized together, or one after the other?Should a quadrotor's airframe and its learned roll controller be sized together? Yes in this stylised model: joint CMA-ES reaches 5.25° RMS roll error, equal to the grid optimum, against 7.06° for lightest-airframe-first; a controller reused across airframes is worse on 41% of them.
- Does the best quadrotor airframe stay best when motor strength, mass and motor lag are randomised?Does the best quadrotor airframe stay best under widened motor-strength, mass and lag randomisation? Mostly: top five unchanged (Spearman 0.75), but retuning gains helps the median airframe 0.91° (stylised).
- Should a quadrotor’s airframe and controller gains be searched jointly when the plant is uncertain?Should airframe and gains be searched jointly under an uncertain plant? Yes in this stylised model: joint CMA-ES at 960 evaluations (5.75° median held-out, 8 seeds) beats random search and a 4800-evaluation grid-then-tune best cell (6.00°).
All 27 Agentic co-design of low-cost robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.