What should a travel creator pack to film from many angles under a weight budget and the 100 Wh battery limit?
research/capture-kit
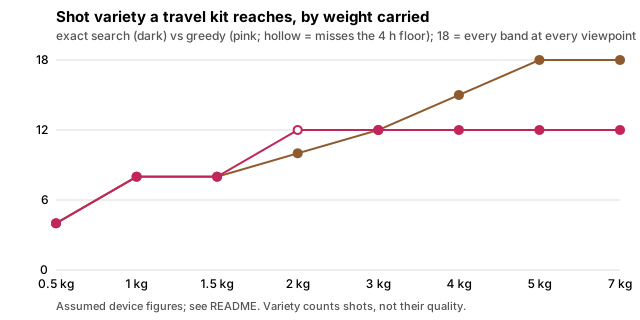
What should a travel creator pack to film from many angles within a weight budget and the 100 Wh battery limit? Exact search over 17,280 kits reaches all 18 band x viewpoint shots at 5 kg; a greedy packer stalls at 12 because lenses need their body (assumed device figures).
What it found
Exact search over 17,280 kits of cameras, lenses, mounts and battery packs (11,520 legal), scoring distinct focal-band × viewpoint shots (18 at most) and recording hours against carried weight. With a 4 h recording floor, exact search reaches 15 shots at 4 kg and all 18 at 5 kg, while a greedy best-gain-per-gram packer stalls at 12 from 3 kg because a lens is worthless without its body. Without a floor, variety-first search returns kits that record only ~2.2 h. Every device figure is assumed (round class-typical numbers, not datasheets); only the 100 Wh limit is sourced.
A figure from its own output
Paper, code and results
More in Autonomous multi-angle capture
- How many cameras, and where, to film a person from every angle?How many cameras, and where, to film a person from every angle? A 30° gap between neighbours needs 13 cameras on a ring (15° needs 25), but depth error is set by convergence angle, not count: a pair's error falls 11× from 5° to 90° (7.3 to 0.64 mm) while 3 vs 16 ring cameras only halves it. Idealised 2-D lower bounds.
- How far apart can cameras be before a reel editor can no longer synthesise the angle between them?How far apart can cameras be before a reel editor can no longer synthesise the angle between them? With exact depth a two-view warp beats cutting to the nearest camera only up to about 30° (24.8 vs 23.6 dB); beyond that holes dominate, and a bystander pulls the limit in to about 15° (ray-traced toy scene; ordering, not decibels).
- Is the depth a camera rig can actually measure good enough for the in-between angle?Is the depth a camera rig can actually measure good enough for the in-between angle? Block-matching stereo on rendered pairs feeds the two-view warp: mean depth error 14.9% at 3 cm baseline to 2.7% at 50 cm, coverage peaks at 91%, and the result never beats cutting to the nearest camera (22.3 vs 24.8 dB at a 15° gap; exact depth 27.3 dB).
- Can the holes and correlated errors of measured stereo depth be repaired so the in-between view beats cutting to the nearest camera?Can the holes and correlated errors of measured stereo depth be repaired so in-between synthesis beats cutting to the nearest camera? A hole filler and a no-ground-truth disagreement gate that falls back to the raw nearest camera lift a 15° gap from 22.3 dB to 29.2 dB against 24.8 dB for cutting (held-out seeds 29.2); with a bystander the gate loses its edge (26.1 vs 26.3 for plain filling). Toy scene.
- Which platform can follow a travel creator through a crowd and keep the shot?Which platform can follow a creator through a crowd and keep the shot? A drone that ignores pedestrians frames 99.9% of the time but falls to 39% at 0.3 people/m² once it avoids them; a wheeled robot is stopped by step lines 42–47% of the walk, and a flat-floor one that ignores people passes within 0.5 m ~500 times an hour. 2-D simulation, assumed platform figures.
- How much of a multi-camera shoot can an automatic edit recover, and what stops it?How much of a multi-camera shoot can an automatic edit recover? At detector noise 0.3 a fixed 3 s rotation shows mean true quality 0.546, a cut-cost (Viterbi) edit 0.802 vs 0.815 on true scores, and best-score-every-frame 0.723 at 345 cuts a minute; clock sync fails first on short clips (5 s at noise 0.25: 25% over 40 ms). Synthetic quality model, no real footage.
All 34 Autonomous multi-angle capture projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.