Which platform can follow a travel creator through a crowd and keep the shot?
research/capture-follow
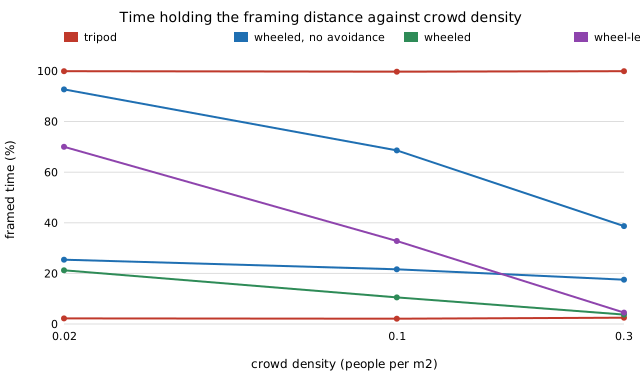
Which platform can follow a creator through a crowd and keep the shot? A drone that ignores pedestrians frames 99.9% of the time but falls to 39% at 0.3 people/m² once it avoids them; a wheeled robot is stopped by step lines 42–47% of the walk, and a flat-floor one that ignores people passes within 0.5 m ~500 times an hour. 2-D simulation, assumed platform figures.
What it found
A 2-D crowd simulation of a tripod, a wheeled robot, a wheel-legged robot and a drone holding a camera 2.5 m behind a walking creator among pedestrians who do not react to it. A drone that ignores pedestrians frames the creator 99.9% of the time at any density, but steering around people drops it to 69% at 0.1 people/m2 and 39% at 0.3; a ground robot on a plaza with curbs and one ramp is stopped 42–47% of the walk, and wheel-legs hold the frame 70% of the time in a thin crowd but 4.5% in a dense one. Avoidance and framing trade off: a flat-floor wheeled robot that ignores people frames 98% of the time while passing within 0.5 m of a pedestrian about 500 times an hour. All platform speeds, powers and masses are assumed; pedestrians do not avoid the platforms, and the drone is not limited by altitude, wind or regulation.
A figure from its own output
Paper, code and results
More in Autonomous multi-angle capture
- How much of a multi-camera shoot can an automatic edit recover, and what stops it?How much of a multi-camera shoot can an automatic edit recover? At detector noise 0.3 a fixed 3 s rotation shows mean true quality 0.546, a cut-cost (Viterbi) edit 0.802 vs 0.815 on true scores, and best-score-every-frame 0.723 at 345 cuts a minute; clock sync fails first on short clips (5 s at noise 0.25: 25% over 40 ms). Synthetic quality model, no real footage.
- When does automatic blurring miss a bystander's face, and which filming platform is conspicuous?When does automatic blurring miss a bystander's face? On an assumed size-recall model a face detector leaves 5% of identifiable faces unblurred per frame, blurring the head of any detected body under 0.1%, and independent per-frame misses show a face in some frame of a 5 s shot 100% of the time; an offline whole-track blur leaves 0 to 5%. No real footage or detector.
- Does recording only when something happens save a travel creator's battery, and what does it cost in missed moments?Does recording only on a trigger save battery, and what does it miss? With 6 thirty-second moments an hour, standby with a 10 s pre-roll uses 19.4 Wh of an 80 Wh continuous day (76% less) and captures 90% of interesting seconds; deep sleep uses 7.7 Wh but captures 69%. Misses and wake latency, not the battery, set coverage. Assumed device figures, synthetic day.
- When a camera rig records only on a trigger, should every camera have its own, or should one wake the rest?When a camera rig records only on a trigger, should every camera have its own, or should one wake the rest? Four standby cameras with their own triggers use 80 Wh of 320 Wh continuous but get all four angles on only 68% of interesting seconds; one sentinel waking the others costs the same and gives 90.5%, and any-camera wake gives 100% for 92 Wh but its false-alarm energy grows with detector count. Assumed device figures.
- Where in a camera ring should the sentinel go when the subject faces a favourite direction?Where in a camera ring should the sentinel go when the subject faces a favourite direction? A sentinel facing the favourite direction misses 8.6% of moments against 34.4% for the one behind; spread cameras' misses are anti-correlated, so capture-wake's independence assumption overstates the all-miss rate by 2x on a ring of 4 and understates it 12x for a tight cluster. With the turned-face miss measured in
capture-detectors(54 faces) in place of the assumed curve, placement matters only if the back of a head goes undetected (untested), and weak detectors miss 8 to 45% of moments even with four cameras listening. - Does a longer window, a lower gamma or a delay prior fix the period aliasing and early-start failures of GCC audio sync on real clips?Does a longer window or a delay prior fix GCC sync's aliasing on real clips? Window length (shared audio) is the lever: 97% wrong at 1 s, 38% at 2 s, 16% at 3 s on the failing clips; a tone clip needs a prior tighter than its period.
All 34 Autonomous multi-angle capture projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.