How much of a predictive follow camera's contact reduction survives noisy, delayed pedestrian detections?
research/capture-followtrack
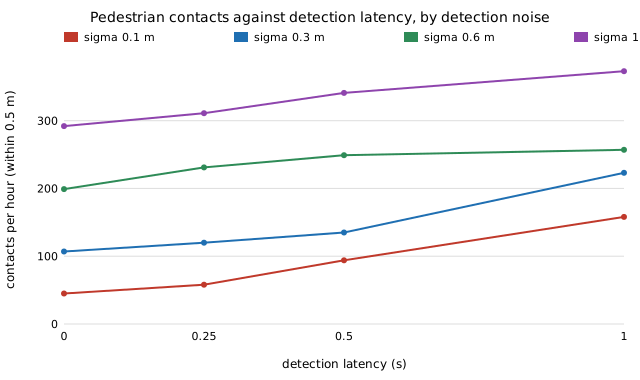
How much of a predictive follow camera's contact reduction survives noisy, delayed pedestrian detections? Framing is unchanged (57-61%) but a drone's contacts rise from 36 per hour with exact data to 120 at 0.3 m noise and 0.25 s delay, and 373 at 1 m and 1 s (ignoring pedestrians: 523). 2-D simulation, swept noise, perfect association assumed.
What it found
capture-followplan's planner cut a drone's close passes (within 0.5 m) at 0.1 people/m² from 523 to 36 per hour, but it was handed exact pedestrian positions and velocities. Here a constant-velocity Kalman tracker over detections with Gaussian noise (0.1 to 1.0 m) and latency (0 to 1 s) feeds it instead, on the same 8 crowds. Framing is unchanged (57 to 61%, against 58.0% with exact data); contacts are not: 45 at 0.1 m noise and no delay, 120 at 0.3 m and 0.25 s, 199 to 257 at 0.6 m, 373 at 1.0 m and 1 s. The planner beats exact-data repulsion (161) only while noise is about 0.3 m or less and latency under about 0.5 s, and that comparison favours repulsion, which was not rerun with noisy inputs. Assumed, not measured: perfect detection-to-track association, independent Gaussian noise, the filter's process noise, and capture-follow’s round-number platform figures; the noise levels are a sweep, not a detector’s datasheet.
A figure from its own output
Paper, code and results
More in Autonomous multi-angle capture
- What does it cost a travel filming kit to also carry its footage backup?What does it cost a travel filming kit to carry its footage backup? Counting storage costs 3 of 18 shots at 4 kg; the lightest kit reaching all 18 grows from 3,900 g to 4,125 g.
- Can a small model trained on many random scenes choose the per-pixel blend weight for stereo-depth view synthesis better than a hand-set ramp?Can a small model trained on many random scenes pick the per-pixel blend weight better than a hand-set ramp? A one-hidden-layer network beats the best soft gate by 0.57 dB on 40 held-out scenes (all 40 ahead) and recovers 0.36 of the headroom to the best per-pixel blend.
- Does the audio-sync threshold found on synthetic noise hold on real recorded sound?Does the synthetic audio-sync threshold hold on real sound? No: on 10 real clips 2 s windows fail 53% of the time at -10 dB SNR (0% synthetic), and partial whitening instead of PHAT halves that.
- Does an automatic multi-camera edit survive the audio-sync errors measured on real recorded clips?Does an automatic multi-camera edit survive sync errors measured on real clips? Not as on synthetic audio: 34% of cuts jump over a frame at 0 dB SNR (64% at -10 dB) against none, depending on the clip; partial whitening cuts the 0 dB figure to 1.4%.
- Does the capture-kit packing result survive real, sourced device weights, energies and runtimes?What does the capture-kit packing result look like with real, sourced devices (Insta360 X4, DJI Osmo Action 4, iPhone 15 Pro Max, Sony a7C II and lenses, Anker packs)? Exact search reaches all 18 shots at 4 kg, greedy stalls at 12; the unsourced mount masses move the exact figure by up to 10 shots.
- Does trimming sync windows by their distance from the fitted clock line, with no tuned threshold, beat the peak-sharpness gate on real audio?Does a clip-free residual-from-the-clock-line trim beat the PSR gate? At 0 dB a little (1.4% to 0.9% of cuts over a frame); at -10 dB no (46% vs 38% for PSR).
All 34 Autonomous multi-angle capture projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.