How small can a face or a person be before a real detector stops finding it?
research/capture-detectors
How small can a face be before a real detector misses it? YuNet found every face of 16 px or wider and half at 10 px (assumed: 20), cutting the modelled blur leak on an 8K 360 camera from 4.8% to 0.01%; YOLOX finds half of people at 23 px tall. A pilot on 22 easy faces in 128 COCO photos: an optimistic bound.
What it found
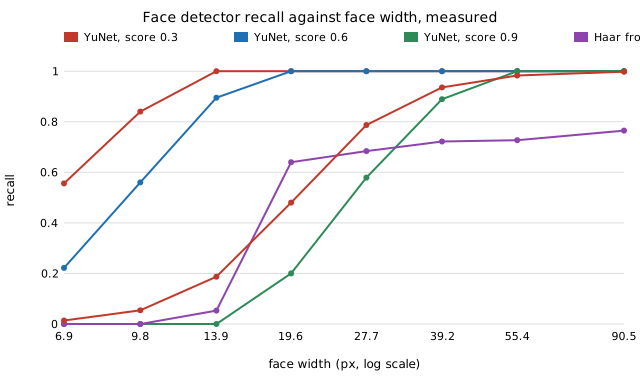
Measured recall against pixel size for real detectors on COCO photos, replacing the assumed curve in capture-bystander. 22 confident faces and 254 labelled people from 128 photos were shrunk by scales from 1 to 0.065 and each detector asked to find them again. YuNet at its usual 0.6 score found every face of 16 px or wider and half at 10 px (fitted 50% point 9.2 px, range 8.2–10.4), not the assumed 20; at a 0.9 threshold it is 26.6 px. On an 8K 360 camera the per-frame leak among faces of at least 32 px falls from the assumed 4.8% to 0.01% (36% to 0.9% at 16 px), and rises to 7.2% at the 0.9 threshold. A YOLOX-s person detector reaches 52% at 20–32 px of height and 94% at 96–128 px (50% point 23 px, not 40); the head sits in the top quarter to third of its box. Section F: by how far the face is turned from the camera, YuNet at 0.9 falls from 54% to 16% recall (54 faces) and the frontal Haar cascade from 66% to 16%, while YuNet at 0.6 holds 95%+; the turn is a landmark proxy and back-of-head is not covered. A pilot: the reference faces are easy by construction (frontal, confident), the photos are shrunk not distant, and n is small, so these are optimistic bounds; the identifiable size is still assumed.
A figure from its own output
Paper, code and results
More in Autonomous multi-angle capture
- Does a predictive gap-seeking planner recover the framing a follow camera loses when it avoids pedestrians?Does a predictive planner recover the framing a follow camera loses by avoiding pedestrians? Not at equal settings (drone 58% framed vs 68% for repulsion at 0.1 people/m²), but it halves-to-tenths the contacts (36 vs 161 per hour; wheeled 21 vs 326) and moves the framing/contacts front left. 2-D simulation, assumed platform figures.
- How much of a predictive follow camera's contact reduction survives noisy, delayed pedestrian detections?How much of a predictive follow camera's contact reduction survives noisy, delayed pedestrian detections? Framing is unchanged (57-61%) but a drone's contacts rise from 36 per hour with exact data to 120 at 0.3 m noise and 0.25 s delay, and 373 at 1 m and 1 s (ignoring pedestrians: 523). 2-D simulation, swept noise, perfect association assumed.
- What does it cost a travel filming kit to also carry its footage backup?What does it cost a travel filming kit to carry its footage backup? Counting storage costs 3 of 18 shots at 4 kg; the lightest kit reaching all 18 grows from 3,900 g to 4,125 g.
- Can a small model trained on many random scenes choose the per-pixel blend weight for stereo-depth view synthesis better than a hand-set ramp?Can a small model trained on many random scenes pick the per-pixel blend weight better than a hand-set ramp? A one-hidden-layer network beats the best soft gate by 0.57 dB on 40 held-out scenes (all 40 ahead) and recovers 0.36 of the headroom to the best per-pixel blend.
- Does the audio-sync threshold found on synthetic noise hold on real recorded sound?Does the synthetic audio-sync threshold hold on real sound? No: on 10 real clips 2 s windows fail 53% of the time at -10 dB SNR (0% synthetic), and partial whitening instead of PHAT halves that.
- Does an automatic multi-camera edit survive the audio-sync errors measured on real recorded clips?Does an automatic multi-camera edit survive sync errors measured on real clips? Not as on synthetic audio: 34% of cuts jump over a frame at 0 dB SNR (64% at -10 dB) against none, depending on the clip; partial whitening cuts the 0 dB figure to 1.4%.
All 34 Autonomous multi-angle capture projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.