How long a step can a stock Unitree G1 or H1 take carrying lumber, and does that beat a labourer's carry rate?
research/buildbot-carry
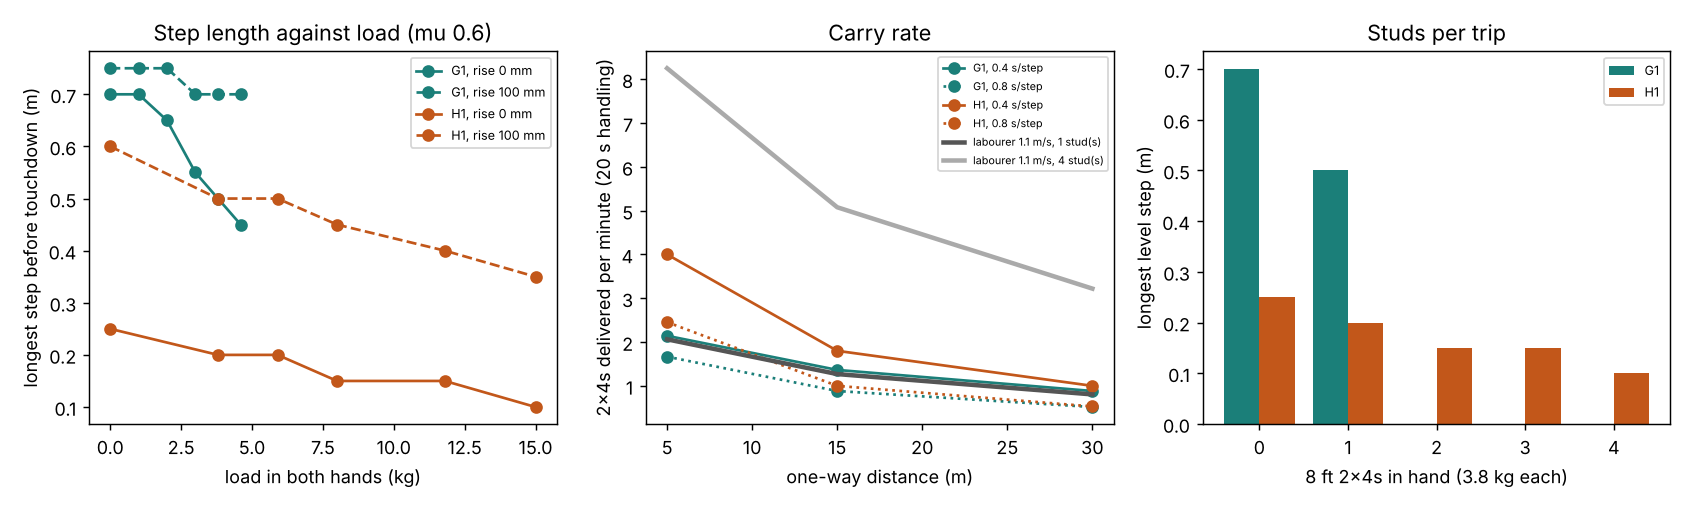
Can a stock humanoid carry a stud faster than a labourer? A MuJoCo single-support step envelope: the G1 steps 0.50 m with one 2x4 and cannot carry two; the H1 steps 0.20 m with one and 0.10 m with 15 kg; neither beats a labourer who takes a bundle of four, and the model is restrictive (no falls, drops or energy scored).
What it found
A model-based single-support envelope, not a walking policy: the pose just before touchdown (stance sole planted, swing sole landing L ahead and s higher, centre of mass L/2 ahead with the linear-inverted-pendulum acceleration applied as tilted gravity), solved in MuJoCo against each joint’s peak torque and a friction limit. At the stud-carry pose the G1 steps 0.70 m unloaded, 0.50 m with a 3.8 kg 2x4 (waist pitch binds) and cannot carry two; the H1 steps 0.25 m unloaded and 0.10 m with 15 kg and cannot climb a 7¾ in riser. Turned into carry rates over 5–30 m trips, a G1 delivers 0.64–1.10× a one-stud labourer and 0.16–0.27× a labourer with four studs; an H1 with 3–4 studs 0.66–1.94× and 0.16–0.48×. Labourer speed, bundle size, handling time and step time are assumed and swept. The gait is restrictive (flat soles, ZMP at the sole), so the H1 figures sit far below Unitree’s own claims; no falls, drops or energy were scored.
A figure from its own output
Paper, code and results
More in Robots on the building site
- Does planning the centre of pressure off the middle of the sole let a stock humanoid carry faster?Does moving the planned centre of pressure along the sole raise a humanoid's carry speed? Not by a constant offset: the G1's 4 kg result moves one grid cell (0.10 to 0.13 m/s) and joint torques, not the sole, set the limit.
- Can a stock Unitree G1 or H1 humanoid carry a stud across a site floor as fast as a labourer?Can a stock Unitree G1 or H1 carry a stud as fast as a labourer? A pendulum gait with no trunk compensation gets the G1 to 0.25 m/s unloaded and 0.10 m/s at 4 kg; a robot with one piece per trip would need 4-13 m/s to match a labourer carrying three.
- Does sweeping the planned centre of pressure from heel to toe let a stock humanoid carry faster?Does a heel-to-toe sweep of the planned centre of pressure raise a humanoid's carry speed? No: one grid cell for the G1 at 4 kg and the unloaded H1, and nothing for heavier loads, because joint torques set the limit.
- Can a stock Unitree G1 or H1 humanoid hold one end of a sheet while a person lifts the other?Can a stock Unitree G1 or H1 hold one end of a sheet while a person lifts the other? For a 22 kg sheet the person carries 11.1-11.5 kg-equivalent in a 2-4 s lift; the G1 manages up to 8 kg, the H1 a 23 kg drywall sheet; lag sets the tilt (2-6 degrees at 0.2-0.5 s).
- Does a stock humanoid pay for itself on a house site, and how much of a new home's price could it remove?Does a stock humanoid pay for itself on a house site? The break-even slowdown against a $38/h loaded carpenter is about 2.4 for a $16k Unitree G1 and 1.1 for a $90k H1; over a sweep the G1 saves money in 15% of draws, the H1 in 0.4%, and a perfect H1 would remove 0.19% of an average home's price on the taskbook scope (inputs swept, not measured).
- Does a purpose-built nailing gantry beat a stock humanoid at fastening sheathing, and at what house volume does it pay?Does a purpose-built nailing gantry beat a stock humanoid at fastening sheathing? A modelled two-axis bridge nails a 62-nail sheet in 61 s (6.1x hand nailing); a $100k machine needs about 150 houses a year to break even on walls (50 with roof cassettes), where the H1 saves money in 0.4% of draws (price and times swept, not sourced).
All 27 Robots on the building site projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.