Can a stock Unitree G1 or H1 humanoid carry a stud across a site floor as fast as a labourer?
research/buildbot-carryphase
Can a stock Unitree G1 or H1 carry a stud as fast as a labourer? A pendulum gait with no trunk compensation gets the G1 to 0.25 m/s unloaded and 0.10 m/s at 4 kg; a robot with one piece per trip would need 4-13 m/s to match a labourer carrying three.
What it found
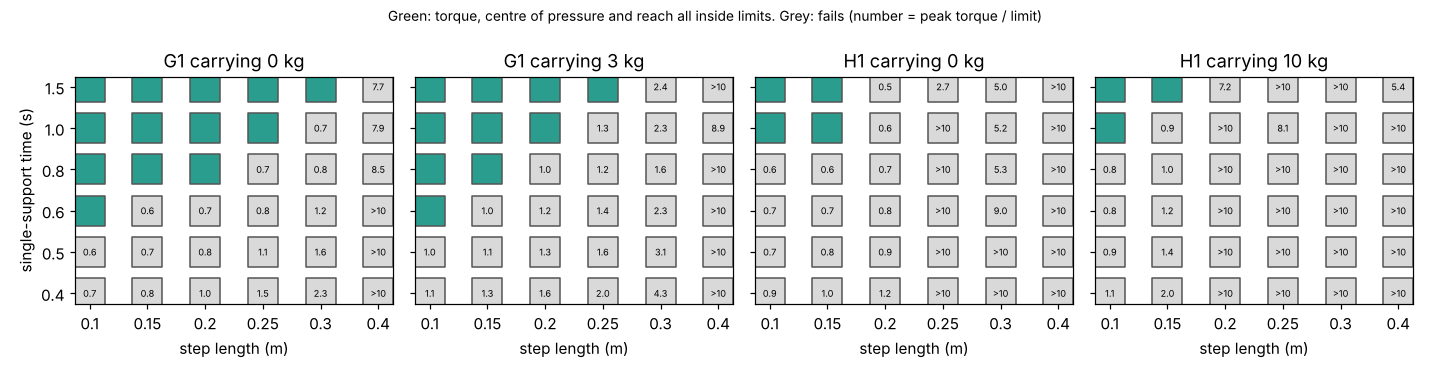
Single-support inverse dynamics of the Menagerie G1 and H1 carrying a load along a prescribed linear-inverted-pendulum gait (636 cases over payload, step length, step time, ramp and step-up), scored against joint torque limits and the sole. The G1's fastest feasible step is 0.25 m/s unloaded and 0.10 m/s at 4 kg (none at 5 kg); the H1's 0.15 m/s unloaded and 0.07 m/s at 14 kg. A 1:12 ramp leaves the G1's speed unchanged; the H1 finds no step on a ramp. These are pessimistic lower bounds, because the gait has no trunk compensation and the centre of pressure leaves the sole first. A robot holding one piece per trip would have to walk 4–13 m/s to match a labourer carrying three over a 40 m haul, so it loses even at the vendor's quoted ~2 m/s. Preliminary: a prescribed gait and not a policy, falls and energy not scored; the step width, handling times and pieces per trip are my assumptions, swept; nothing is a safety case.
A figure from its own output
Paper, code and results
More in Robots on the building site
- Does sweeping the planned centre of pressure from heel to toe let a stock humanoid carry faster?Does a heel-to-toe sweep of the planned centre of pressure raise a humanoid's carry speed? No: one grid cell for the G1 at 4 kg and the unloaded H1, and nothing for heavier loads, because joint torques set the limit.
- Can a stock Unitree G1 or H1 humanoid hold one end of a sheet while a person lifts the other?Can a stock Unitree G1 or H1 hold one end of a sheet while a person lifts the other? For a 22 kg sheet the person carries 11.1-11.5 kg-equivalent in a 2-4 s lift; the G1 manages up to 8 kg, the H1 a 23 kg drywall sheet; lag sets the tilt (2-6 degrees at 0.2-0.5 s).
- Does a stock humanoid pay for itself on a house site, and how much of a new home's price could it remove?Does a stock humanoid pay for itself on a house site? The break-even slowdown against a $38/h loaded carpenter is about 2.4 for a $16k Unitree G1 and 1.1 for a $90k H1; over a sweep the G1 saves money in 15% of draws, the H1 in 0.4%, and a perfect H1 would remove 0.19% of an average home's price on the taskbook scope (inputs swept, not measured).
- Does a purpose-built nailing gantry beat a stock humanoid at fastening sheathing, and at what house volume does it pay?Does a purpose-built nailing gantry beat a stock humanoid at fastening sheathing? A modelled two-axis bridge nails a 62-nail sheet in 61 s (6.1x hand nailing); a $100k machine needs about 150 houses a year to break even on walls (50 with roof cassettes), where the H1 saves money in 0.4% of draws (price and times swept, not sourced).
- Can a stock Unitree G1 or H1 humanoid push a nailer into a wall and place nails inside a stud face?Can a stock Unitree G1 or H1 push a nailer into a wall and place nails inside a stud face? One 4x8 sheet is 62 nails, 34 with a +-3.9 mm window; the tip needs 1.24 mm scatter for a 95% sheet. The G1 pushes up to 142 N and reaches 18 of 62 nails from one stance, the H1 up to 276 N and 36 of 62 (static, peak torque, no policy).
- Can a G1 humanoid nail a 4x8 sheet lying flat on a table?Can a G1 humanoid nail a 4x8 sheet lying flat on a table? Not better than on a wall: pushing down at 50 N with its feet planted it holds only 30 of 693 reach cells, reaching 48 of the sheet's 62 nails in 16 stances (13 stances for all 62 on a wall), and matching hand nailing (372 s) only if each re-stance takes under 23-24 s (push, standoff and re-stance time are swept, not sourced; static IK, no walking).
All 27 Robots on the building site projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.