How many verifiers does deterrence-by-audit need?
research/audit-staffing
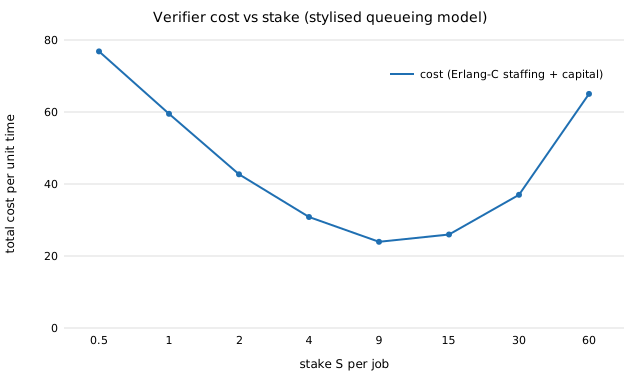
Staffing the audit pool that stake-based deterrence needs: exact Erlang-C waiting (matches simulation), square-root staffing R+1.06√R (spare capacity 60% at R=5, 1.1% at 10⁴), stake–headcount optimum G+S=√(wsG/(rd₀)) (cost 24 vs 77 at too little stake), and bursty audit demand delays 1.8× what Allen–Cunneen predicts.
What it found
Stake sets the audit rate a = G/(G+S); the audits then form a queue with offered load R = λas. Erlang-C waiting matches simulation (P(wait) 0.409 vs 0.407), and square-root staffing c = R + 1.06√R is within 1.5 servers of the exact minimum for R ≥ 100, so the spare capacity needed falls from 60% at R=5 to 1.1% at 104. Stake and headcount trade off with first-order optimum G+S = √(ws G/(rd0)): total cost 23.6 at the optimum versus 76.8 with too little stake and 65 with too much. Heavy-tailed audit times make Allen–Cunneen pessimistic (0.97 vs 0.63); batches of simultaneous audits make it optimistic (0.82 vs 1.45 at batch size 4). Stylised costs, FIFO, static outages.
A figure from its own output
Paper, code and results
More in Verification games & slashing
- Escalating bonds: cheap challenges, fixed deterrence, a γ-fold capital asymmetryEscalating-bond dispute games: exact deterrence opening bond
εV/((1−ε)C−εD)shrinks geometrically in rounds while the attacker's total outlay barely moves, and a sharp capital race where the defender needsγ·max{C(r) ≤ B_C}≤γ·B_C. - How wide should a dispute bisect?K-ary bisection dispute games: optimal arity solves
k ln k − k + 1 = a/b(binary only ifa/b ≤ 0.386), 1.9–6× cheaper than binary at T=10⁶, adaptive schedules gain ≤1%, leaf-size trade-off, latency as extra round cost. - Can stake shorten a challenge window when proposers can be bribed?Optimistic-verification challenge windows with bribable proposers: exact gamble-then-bribe attacker recursion, closed-form window, stake cannot shorten it under an exogenous bribe price (63 blocks for S=10…1600), bounty-funded priority fees give
S·w ≈ G/((1−ρ)θ). - How much does an appeal ladder of juries buy, and what must appeals cost?Escalating jury appeal ladders with fee-priced appeals: an exact fee window makes error
∏(1−M_k), 11 jurors is the smallest deterring panel at prize 100, 3→11→27 errs 2.4e-4 at 5.8 expected seats vs 12.6% for one 7-seat panel, shared jury bias sets a floorρ(1−a). - Do free retries break hash-derived spot checks?Hash-derived audit challenges under free retries: cheat profit exactly
G − c/p, deterrence needsln(G/c)·T/kopened steps vsln2·T/kfor a beacon (10×–60×), stake is irrelevant, and the proof-of-work optimum isx* = v/λ_p − c0. - When do verifiers complement rather than substitute?Verifiers as informational complements: decision value is zero below a closed-form committee size while mutual information is submodular; myopic hiring buys nothing and leave-one-out pay is a sawtooth that vanishes.
All 19 Verification games & slashing projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.