A heartbeat twin that drops packets independently: how often does the real bursty link trip a missed-beat watchdog, and what timeout is safe?
research/watchdog-twin
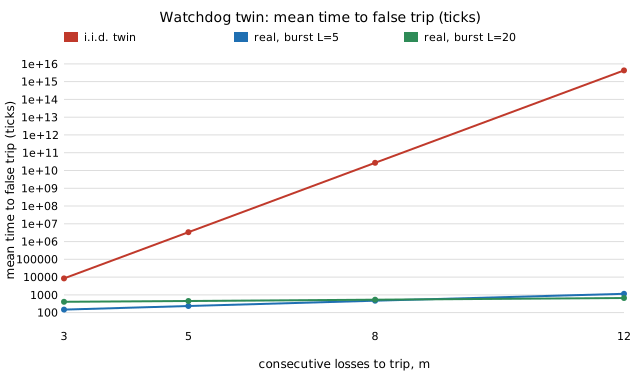
I.i.d.-loss heartbeat twin vs a bursty Gilbert link: a 5-missed-beat watchdog false-trips every 3.4e6 ticks in the twin but every 235–990 on the real link, worst at burst length ≈ m (mean time to trip ≈ e·m/p), and a 1e6-tick target needs m = 16–154 instead of the twin's 5. Stylised.
What it found
At 5% mean loss a watchdog that e-stops after m = 5 missed heartbeats false-trips once in 3.4×10⁶ ticks (18.7 h at 50 Hz) in the i.i.d.-loss twin but every 235–990 ticks (5–20 s) on a two-state bursty link with mean burst 2–50, from an exact recursion checked against enumeration and Monte Carlo. The error is not monotone in burst length: it is worst at L ≈ m, where the mean time to trip is only ≈ em/p. For a 106-tick target the twin picks m = 5 (0.10 s to detect a dead link) while the real link needs 16–154 (0.3–3.1 s) growing linearly in L, and with L unknown no affordable timeout guarantees it. Stylised: Gilbert channel, plain miss counter, no link traces.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- A twin whose sensor never produces outliers: does an innovation gate help or hurt the real estimator, and what does it do after a jump?Gaussian-sensor twin vs a real sensor with outliers under an innovation gate: the twin says the gate costs 8.5% MSE, the real sensor gains 3.0× from it, the worst outlier scale for a gated filter is finite (κ≈4) while ungated error grows as κ², and a gate locks out recovery from a jump for ≈76·D² steps. Stylised.
- A twin without ground effect: where does a landing altitude loop go wrong?Rotorcraft altitude twin without ground effect vs real thrust gain
1/(1−(R/4z)²): hover sits 18 mm high at one rotor radius (twin: 0), and a delayed loop with 28% twin headroom goes unstable at 0.54 rotor radii. Stylised. - What does a linear photon-counter twin of a SPAD lidar miss about dead time?Linear photon-counter twin of a SPAD lidar vs dead time: half the flux reported at nτ=1, a paralyzable-detector ambiguity (one reading, two fluxes, 12.7× apart at mτ=0.2), first-photon range bias −N/(2√π)σ saturating near −2σ (−22.6 cm at N=10, σ=1 ns) that does not average out, and a Coates correction that removes it. Stylised.
- What ghost ranges does a single-ray lidar twin never produce at a depth edge?Single-ray lidar twin vs a finite beam with merged pulses at a depth edge: ghost-range band exactly
2Φ⁻¹(1−ε/D)beam widths (2.56 at ε/D=0.1, none at ε≥D/2), shifts and narrows for unequal brightness, matches a scan simulation to 0.3%, and a 3-of-5 persistence filter still passes 80–99% of ghosts. - What does an FMCW radar twin without range–Doppler coupling get wrong about a moving target?FMCW range–Doppler coupling: a twin that reads true range misses a bias of
f_D Tcells (0.6–4.8 at 30 m/s), signal-level check ≤1e-4 cells, wrapped-Doppler compensation is worse than none on half of the over-range speeds, and a ±60° stationary scene leaves0.71κvposition bias plus0.46κvdistortion. - Does a well-featured twin overstate scan-matching accuracy in a corridor, where the scan cannot see the along-track direction?Scan matching in a corridor: along-track information is exactly zero without door frames, 1.6–6× a room's along-track sd with them; a filter fed the room twin's covariance has NEES 432–1535 over a blind span, and the exact covariance holds only inside a ~0.2 m basin. Stylised.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.