What does a linear photon-counter twin of a SPAD lidar miss about dead time?
research/deadtime-twin
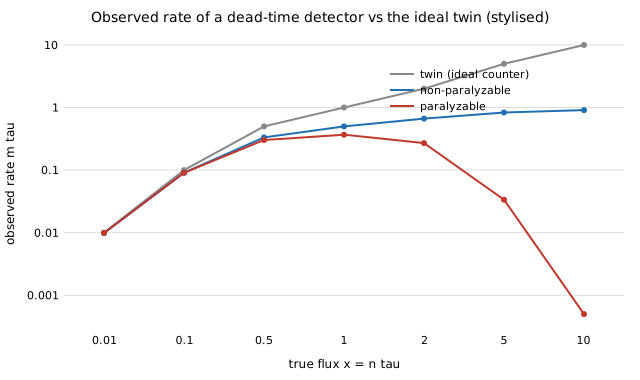
Linear photon-counter twin of a SPAD lidar vs dead time: half the flux reported at nτ=1, a paralyzable-detector ambiguity (one reading, two fluxes, 12.7× apart at mτ=0.2), first-photon range bias −N/(2√π)σ saturating near −2σ (−22.6 cm at N=10, σ=1 ns) that does not average out, and a Coates correction that removes it. Stylised.
What it found
An ideal counter twin reads flux linearly; a real detector with dead time τ reports half the flux at nτ=1 (non-paralyzable) or 36.8% (paralyzable), and the paralyzable curve peaks at 1/e, so one reading has two fluxes (0.259 or 2.543 at mτ=0.2; a twin is 12.7× too low on the high branch). First-photon timing of a Gaussian pulse is biased early by −N/(2√π)σ at small N (exact) and saturating near −2σ: −0.28σ at N=1 and −1.50σ at N=10 (−22.6 cm for σ=1 ns) while the spread shrinks to 0.62σ, so it is bias, not averaging noise. A Coates correction of the first-photon histogram restores the mean to within 0.02σ. Stylised: one pulse, no background light, afterpulsing or crosstalk.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- What ghost ranges does a single-ray lidar twin never produce at a depth edge?Single-ray lidar twin vs a finite beam with merged pulses at a depth edge: ghost-range band exactly
2Φ⁻¹(1−ε/D)beam widths (2.56 at ε/D=0.1, none at ε≥D/2), shifts and narrows for unequal brightness, matches a scan simulation to 0.3%, and a 3-of-5 persistence filter still passes 80–99% of ghosts. - What does an FMCW radar twin without range–Doppler coupling get wrong about a moving target?FMCW range–Doppler coupling: a twin that reads true range misses a bias of
f_D Tcells (0.6–4.8 at 30 m/s), signal-level check ≤1e-4 cells, wrapped-Doppler compensation is worse than none on half of the over-range speeds, and a ±60° stationary scene leaves0.71κvposition bias plus0.46κvdistortion. - Does a well-featured twin overstate scan-matching accuracy in a corridor, where the scan cannot see the along-track direction?Scan matching in a corridor: along-track information is exactly zero without door frames, 1.6–6× a room's along-track sd with them; a filter fed the room twin's covariance has NEES 432–1535 over a blind span, and the exact covariance holds only inside a ~0.2 m basin. Stylised.
- A twin whose sensor never produces outliers: how many particles does a bootstrap filter need, and is the average effective sample size the right thing to size on?Gaussian-sensor twin vs outliers for a bootstrap particle filter: exact ESS fraction
c₀e^{−ay²}, the mean ESS barely moves (0.671 vs 0.645) while P(ESS<1%) rises 120× (2.5e-4 → 3.1e-2), a twin-sized N=528 fails 4.4% of real steps, and posterior-mean error is 45–421× the twin's. - Can a fixed inflation radius stand in for a rectangular robot's footprint in a narrow gap?Point/circle/calibrated-inflation footprint twin vs a rectangular robot with heading error in a narrow gap: exact pass probability
2Φ(θ*/σ)−1, circle twins are step functions, a 95%-calibrated inflation is 0.17 m too small at 3× the heading error, 10-gap missions succeed 0.60 where the twin says 1. - If a twin gives every scene the same inlier fraction, how many RANSAC iterations does it say we need, and is that enough when real scenes vary?RANSAC iteration budget from a fixed-inlier-fraction twin (17 for 99%) vs scenes with beta-binomial inlier counts: exact failure 1.3–30% at that budget, 99% needs 19–458 iterations or is unreachable for κ≤2; stylised, line fitting only.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.