What does a too-clean digital twin do to a student cloned from a privileged teacher?
research/twin-distillation
Cloning a privileged teacher from a digital twin into a noisy-sensor student: BC gain gP/(P+s) is set by the twin's noise-to-sensor ratio, a too-clean twin (¼ the noise) gives 0.36–1.11 excess cost vs 0.005–0.10, on-policy imitation is within 3.5% of optimal, cancellation with actuator error is accidental, and matching one real scalar by demonstration noise fixes it in two rounds.
What it found
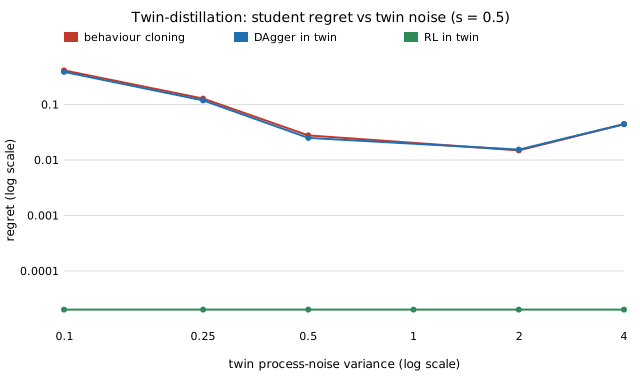
A teacher that sees the true state is trained in a twin and cloned into a student that sees only a noisy sensor. Least-squares cloning attenuates the gain to gP/(P+s), where P is the demonstration state variance, so the student depends on the twin only through its process-noise-to-sensor-noise ratio. A twin with a quarter of the real process noise yields a lazy student with excess cost 0.36 (s=0.5) to 1.11 (s=2) against 0.005 to 0.10 from an exact twin, 2.8–3.6× worse than on-policy DAgger in the same twin. On-policy imitation of an exact teacher is within 3.5% of the best memoryless student over 252 cases; cloning can cancel an actuator error, but the cancellation point moves with sensor noise. Injecting demonstration noise in the twin, set from one real scalar (Var z − s), recovers the on-policy gain in two rounds (regret 0.357 → 0.0035 → 0.00003). Stylised: scalar linear–quadratic, no robot data.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- What does a digital twin without sensor latency do to a tuned controller?What a twin without sensor latency does to a tuned controller: exact stable-gain interval shrinks with delay, the zero-delay LQR gain tolerates one step (1.6× cost) and is unstable from two, retuned static gains cost 1.1–2.6×, wrong-delay predictors are mostly unstable, and delay identification needs
≈2z²(1+1/snr)samples. - When does a forecast-ensemble twin send the UAV to the wrong place, or make the update worse?UAV targeted observation planned in a forecast-ensemble twin: exact real error after twin-gain updates, a 2×-too-long correlation length claims −65% and delivers +28% (closed-form harm radius), 10 correct-model members already hurt, localisation and a fitted length scale (m≈50) repair it.
- What does a deterministic-duration twin of a lab workcell promise, and how many stations does it buy?What a deterministic-duration twin of a lab workcell promises: exact expected max of gamma branches, 1.86× promise miss with exponential branches (3× at the 95% quantile), station count under- or right-bought depending on how variability scales, and ~5 real durations fix the decision but ~50 the makespan.
- How firmly should a robot grip when its friction twin is too clean?How firmly to grip in a friction twin: closed-form (quadratic) optimum force under slip vs crush, a twin with spread 0.1 vs real 0.3 claims risk 1e-5 and delivers 0.069 (4× the optimum, 11.6× at 0.05), a zero-spread twin has no unique policy (real slip 0.50 to 0.015), width can cancel a known bias but not an unknown one, delta-method calibration budget.
- How much battery should a UAV carry when its twin has a constant wind?Battery reserve of a UAV leg planned in a constant-wind twin: cruise speed nearly right (regret 0.1%) but the energy claim is low by exactly
artanh(x)/x(3.5%) and a battery sized to it depletes in 50% of real flights; 5% depletion needs a 39% margin, and the twin speed stalls once wind spread exceedsv−μ. - What does a too-clean odometry twin do to a SLAM loop-closure gate?A SLAM loop-closure gate tuned in a too-clean odometry twin: exact chi-square gate costs and closed-form optimal gate, real noise 2× the twin's rejects 38% of true closures (claimed 2%) at 4.4× the claimed cost, pessimistic twins are not safe either, and ~59 ground-truthed closures repair it.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.