What does it cost to make workers race?
research/speed-race
Paying the first k of n finishers makes speed a contest: π'(1)=(1−k/n)(H_n−H_{n−k}), equilibrium speed R(n−k)(H_n−H_{n−k})/(nc), exact round time nc/((n−k)R); paying all finishers buys no speed, a budget favours winner-take-all until an accuracy floor k_min binds, and recruiting more workers barely speeds the round.
What it found
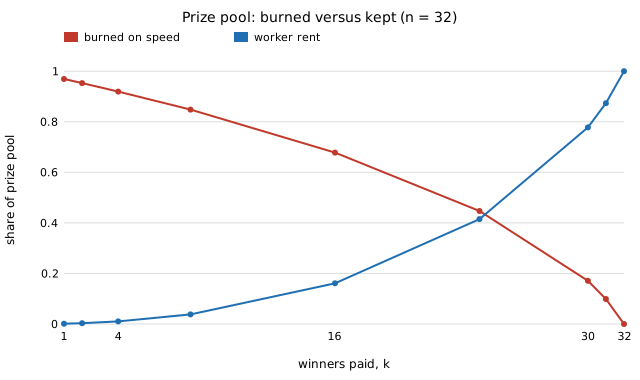
If a round pays the first k of n finishers a prize R and workers buy speed at cost c per unit rate, the win probability’s slope at the symmetric point telescopes to (1−k/n)(Hn−Hn−k), so equilibrium speed is R(n−k)(Hn−Hn−k)/(nc) and the round time is exactly nc/((n−k)R). Paying every finisher buys no speed at all; for a fixed budget, speed alone wants winner-take-all (0.10 at k=1 versus 3.2 at k=16 for n=32), and only the statistical floor on k justifies more winners. Recruiting more workers barely helps: total speed bought saturates at kR/c. Exponential races, linear cost, symmetric risk-neutral workers; equilibrium checked on a grid.
A figure from its own output
Paper, code and results
More in Paying contributors
- Who drops out of a race when workers have unequal costs?Paying the first k of n finishers when costs differ: proof of the
π'(1)telescoping identity, exact exit rule (slow workers idle iffc_s/c_f ≥ n_f/(n_f−k), never fork ≥ n_f), cost ratio 4 excludes slow workers fork ≤ 3of 4 fast, convex costs make headcount buy speed. - How much accuracy can a market buy from contributors who value their privacy?Buying private data with a telescoping log-score market: payment equals information, best Gaussian-mechanism noise in closed form, participation iff
κa<1so precision is capped atλ/(cΔ²)for any number of contributors, and early arrivals over-collect (1–22% welfare loss). - Paying for improvements, not for overfittingPaying for model improvements against a hidden holdout: telescoping budget, a payment-feedback overfitting attack (paid 0.15 while true loss worsens 0.37), and the Ladder fix with its measured cost.
- What does submitting copies earn under Shapley payments?Shapley and leave-one-out payments under replication: Shapley pays every extra copy even when worthless, saturating at stand-alone value (
(n+2)/2× honest), naive evaluators hand over the pot, LOO pays copies 0 but distributes 1/(n+1), dedup underpays lookalikes by 45%. - How should Shapley payments be sampled and audited?Auditing sampled Shapley payments: exact estimator variances in a saturating game, permutation sampling is exactly efficient but stratified sampling has 6–8× lower variance (zero for equal contributors) at up to 7% budget error, antithetic reversal gives 1.6× lower RMSE, Hoeffding sample counts are 4–5× conservative.
- How precise should a training-contest leaderboard be?Winner-take-all training contests scored on a noisy holdout: effort
V a_n √m/switha_2 = a_3 = 1/(2√π)exactly, a precision ceilingV/σ² ≤ λ_max(n)beyond which no pure equilibrium exists (below the zero-rent limit), and the resulting optimal holdout size.
All 8 Paying contributors projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.