Does tuning the trapezoid's ramp fraction beyond a grid shrink the time-optimal carry's edge, and is it still positive?
research/robofab-rampopt
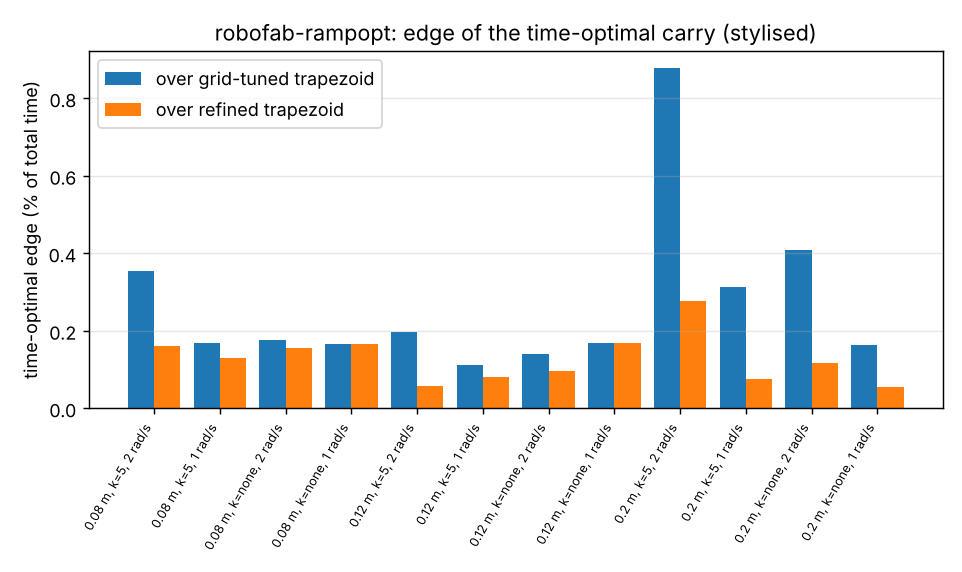
Golden-section tuning of the trapezoid's ramp fraction shrinks the time-optimal carry's edge to +0.05 to +0.28% (still positive in all 12 rows; stylised).
What it found
A follow-up to robofab-edgeconv (stylised). Golden-section refinement of the trapezoid's ramp fraction lowers its six-part total by 0.00 to 0.60% across the twelve speed-limited rows. With the solver at 6400 nodes the time-optimal edge, +0.11 to +0.88% over the grid-tuned trapezoid, falls to +0.05 to +0.28% over the refined one, still positive in every row. The smallest edges are comparable to the solver's residual discretisation error, so their sign is not firmly established. One planar arm, assumed parameters, no motor dynamics; simulated only.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- Is the motor-line edge of the time-optimal carry converged in solver nodes?Repeats the
robofab-motorcurvemotor-line rows with the time-optimal solver at 400, 1600 and 6400 nodes: the edge over the tuned trapezoid moves by at most 0.28 points from 1600 to 6400 (the 0.08 m, k = 2, w0 = 4 row rises from 4.98 to 5.26%), and the missingcoverprofile was a node-count limit. Stylised. - Does the time-optimal carry's edge over a tuned trapezoid survive a motor torque-speed line?Re-solves the nine torque- and jaw-bound
robofab-torqueboundrows with a motor torque-speed line (no-load speed 4 to 20 rad/s): the time-optimal carry stays faster than the tuned trapezoid in all 45 cells, but its edge ranges 3.5 to 28.6% (9.0 to 22.9% under a constant limit), shrinking where a jaw cap binds and growing where only torque does. Stylised. - Is the trapezoid's duration in the torque- and jaw-bound rows set by peaks a sparse check never looked at?Re-checks the nine torque- and jaw-bound
robofab-torqueboundrows with a dense trapezoid peak check (10,000 whole-move samples, 1,000 per ramp, both sides of the acceleration corners): trapezoid totals move by under 0.16% and the time-optimal edge stays 9.5 to 23.0%, so the large edge does not rest on unseen trapezoid peaks. Stylised. - Do the robofab carry results survive an independent physics engine?Re-checks the 108 trapezoid and time-optimal carry profiles of the
robofab-torqueboundrows against MuJoCo inverse dynamics: the hand-written two-link torques agree to 1.8e-5 N m, peaks are within 0.73% of the 5 N m limit (stylised, joint torques only). - Does the time-optimal carry's edge over a tuned trapezoid survive when torque or the jaw cap binds?Re-checks the torque- and jaw-bound rows of
robofab-scurve(no speed limit) with a converged solver and denser trapezoid ramp sampling: the time-optimal carry is still 9.4 to 23.0% faster than the tuned trapezoid in all 9 rows, and the edge is stable to solver node count (under 0.1%) and rises by at most 0.4 points with denser sampling. Stylised. - Once the time-optimal solver's node count is converged, how big is its edge over a tuned trapezoid?Re-solves the time-optimal carry of
robofab-scurvefineat 400 to 25600 nodes in all 12 rows: converged to 0.02% by 6400 nodes, the 400-node answer was up to 0.5% pessimistic, and the converged edge over a ramp-resolved trapezoid is 0.11 to 0.88% in every row; stylised, preliminary.
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.