Is the trapezoid's duration in the torque- and jaw-bound rows set by peaks a sparse check never looked at?
research/robofab-peakcheck
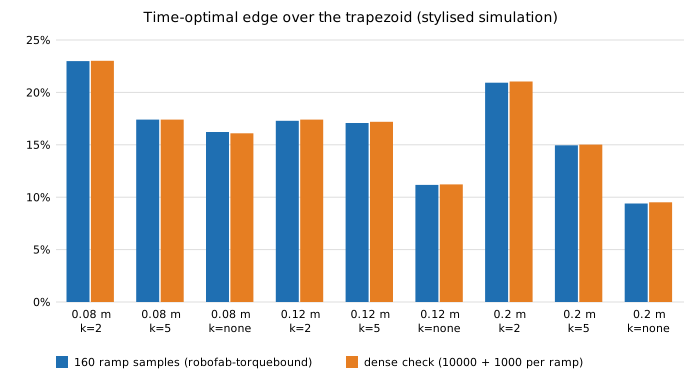
Re-checks the nine torque- and jaw-bound robofab-torquebound rows with a dense trapezoid peak check (10,000 whole-move samples, 1,000 per ramp, both sides of the acceleration corners): trapezoid totals move by under 0.16% and the time-optimal edge stays 9.5 to 23.0%, so the large edge does not rest on unseen trapezoid peaks. Stylised.
What it found
Follow-up to robofab-torquebound (stylised, preliminary). The nine torque- and jaw-bound rows are re-solved with a trapezoid check of 10,000 whole-move samples, 1,000 per ramp and both sides of the acceleration corners, against 201 plus 160 per ramp before. The six-part trapezoid totals change by between −0.15% and +0.15%, the time-optimal edge stays 9.5% to 23.0% (9.4% to 23.0% before), and the dense answers hold at ten times the density with an estimated missed peak of at most 0.25% of a limit. The large edge does not rest on unseen trapezoid peaks. One row goes the other way (dense trapezoid 0.15% faster) and its cause is not investigated. Stylised toy arm; no hardware.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- Do the robofab carry results survive an independent physics engine?Re-checks the 108 trapezoid and time-optimal carry profiles of the
robofab-torqueboundrows against MuJoCo inverse dynamics: the hand-written two-link torques agree to 1.8e-5 N m, peaks are within 0.73% of the 5 N m limit (stylised, joint torques only). - Does the time-optimal carry's edge over a tuned trapezoid survive when torque or the jaw cap binds?Re-checks the torque- and jaw-bound rows of
robofab-scurve(no speed limit) with a converged solver and denser trapezoid ramp sampling: the time-optimal carry is still 9.4 to 23.0% faster than the tuned trapezoid in all 9 rows, and the edge is stable to solver node count (under 0.1%) and rises by at most 0.4 points with denser sampling. Stylised. - Once the time-optimal solver's node count is converged, how big is its edge over a tuned trapezoid?Re-solves the time-optimal carry of
robofab-scurvefineat 400 to 25600 nodes in all 12 rows: converged to 0.02% by 6400 nodes, the 400-node answer was up to 0.5% pessimistic, and the converged edge over a ramp-resolved trapezoid is 0.11 to 0.88% in every row; stylised, preliminary. - How hard must the jaws squeeze while the arm moves?How hard must the jaws squeeze while the arm moves? Simulated minimum force matches the m·sqrt((g+a)²)/(2μ) bound within 7% over 77 cases and is at most 0.3 N at 40 m/s²; a contact time constant that passes the static test reports slip at any force once the jaws accelerate (stylised).
- Does the jaw-force bound still hold at arm accelerations of 100 to 800 m/s²?Does the jaw-force bound still hold at arm accelerations of 100 to 800 m/s²? With fine MuJoCo contact settings the minimum force is 0.89–1.02× the bound over 39 cases; the earlier settings fail above 200 m/s² (stylised, prescribed acceleration, no arm).
- How fine must the MuJoCo contact settings be for a moving grasp?How fine must MuJoCo contact settings be for a moving grasp? On all seven toy-gripper parts,
solref0.2 ms and below reproduce the jaw-force bound (0.98–1.04×) at 100–800 m/s²; 0.5 ms fails at 400 and above, and the adequate value falls with acceleration (stylised, upward load only).
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.