Can a printed gripper assemble its own next generation?
research/robofab-bootstrap
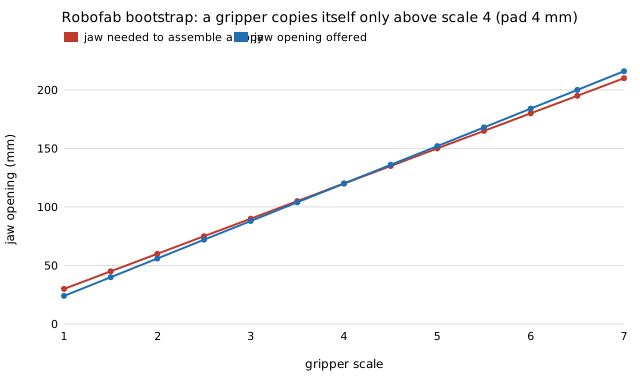
Can a printed gripper assemble its own next generation? With fixed-size jaw pads a gripper builds a copy only at scale ≥ pad thickness in mm (4 mm pads: scale 4); a stroke cap of S mm needs 30·pad ≤ S; seeds of 130 and 140 mm sustain a chain, 60 and 100 mm decay. Largely algebraic given an assumed opening; stylised.
What it found
A follow-up to the self-parts project: the arm that builds generation k+1 is the printed gripper of generation k, with an assumed jaw opening of 32s − 2t mm for fixed-size pads of thickness t. Exhaustive assembly search gives a required opening of exactly 30s mm, so a gripper can build a copy only at scale s ≥ t (scale 4 for 4 mm pads), and a stroke cap S admits one only if 30t ≤ S. Seeds of 130 and 140 mm sustain a chain; 60 and 100 mm seeds shrink and stop. Largely algebraic given the assumed opening; one toy design; simulation only.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- How long an arm does it take to assemble its own toy gripper?How long an arm does it take to assemble its own toy gripper? A planar two-link arm needs 60–140 mm links as the tray moves 40–400 mm away, and a 90° elbow limit more than doubles it (stylised).
- Does the assembly order change the arm an arm needs to build its own gripper?Does the assembly order change the arm needed to build its own gripper? Across all 384 valid orders the shortest arm is identical in every setting tried (negative result, stylised).
- Can friction hold each printed part of a gripper?Can friction hold each printed part of the toy gripper? The simulated minimum jaw force matches the m·g/(2μ) bound to within 5% over 33 cases and is at most 0.1 N, so the jaw opening, not friction, is the constraint (stylised).
- Does arm torque or jaw friction limit how fast an arm carries a printed part?Does arm torque or jaw friction limit how fast an arm carries a printed part? With 0.12 m links and 5 N m the carries take 0.06–0.10 s and the cover needs 1.25 N per jaw (21× static); grip binds below about 0.5 N (stylised, bound extrapolated beyond 40 m/s²).
- How much carry time does a time-optimal move save over min-jerk, and what does it cost the jaws?How much carry time does a time-optimal move save over min-jerk, and what does it cost the jaws? On the
robofab-armaccelarm the six-part total falls by 21 to 29% while the jaw-force bound rises 1.2 to 2.4 times (stylised, assumed parameters). - How fast can an arm carry a printed part when the jaw force is capped as well as the joint torque?How fast can an arm carry a printed part when the jaw force is capped as well as the joint torque? On the
robofab-armbangarm the time-optimal move still beats min-jerk by 17 to 43% under caps of 1.25 to 10 times the static hold force, and a tight cap makes the torque limit irrelevant (stylised, assumed parameters).
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.