Does arm torque or jaw friction limit how fast an arm carries a printed part?
research/robofab-armaccel
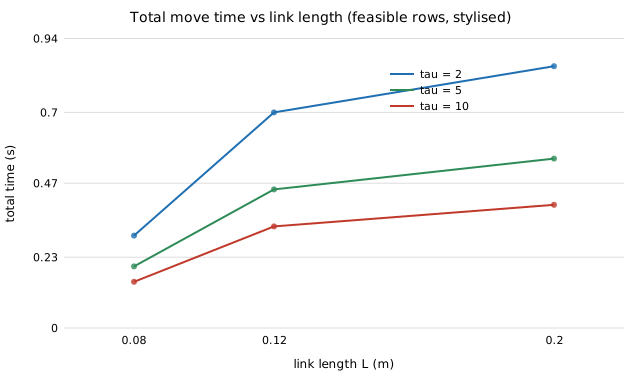
Does arm torque or jaw friction limit how fast an arm carries a printed part? With 0.12 m links and 5 N m the carries take 0.06–0.10 s and the cover needs 1.25 N per jaw (21× static); grip binds below about 0.5 N (stylised, bound extrapolated beyond 40 m/s²).
What it found
A follow-up to robofab-graspmove and robofab-reach: a planar two-link arm with assumed masses carries each of the six free parts of the toy gripper on a min-jerk joint move, as fast as an assumed joint torque limit allows. With 0.12 m links and 5 N m the carries take 0.06 to 0.10 s and the 5.95 g cover needs 1.25 N per jaw, 21× its static force; a jaw force under about 0.5 N makes the grip, not the arm, the limit. A larger arm is slower at a fixed torque. Stylised: assumed masses and torques, and the grip bound, simulated only up to 40 m/s2 earlier, is applied beyond that range.
A figure from its own output
Paper, code and results
More in Robot manufacturing loops
- How much carry time does a time-optimal move save over min-jerk, and what does it cost the jaws?How much carry time does a time-optimal move save over min-jerk, and what does it cost the jaws? On the
robofab-armaccelarm the six-part total falls by 21 to 29% while the jaw-force bound rises 1.2 to 2.4 times (stylised, assumed parameters). - How fast can an arm carry a printed part when the jaw force is capped as well as the joint torque?How fast can an arm carry a printed part when the jaw force is capped as well as the joint torque? On the
robofab-armbangarm the time-optimal move still beats min-jerk by 17 to 43% under caps of 1.25 to 10 times the static hold force, and a tight cap makes the torque limit irrelevant (stylised, assumed parameters). - Does a joint-speed limit erase the time-optimal carry's advantage over min-jerk?Does a joint-speed limit erase the time-optimal carry's advantage over min-jerk? On the
robofab-jawcaparm it grows it: 28 to 46% shorter under speed limits of 6 to 1 rad/s, tending to the 47% set by the min-jerk profile shape (stylised, assumed parameters). - Is the time-optimal carry's speed-limited advantage just the min-jerk profile's shape?Is the time-optimal carry's speed-limited advantage just the min-jerk shape? Against a tuned trapezoidal-velocity move it is only 0.4 to 2.9% at speed limits of 2 and 1 rad/s (46% over min-jerk), and 8.7 to 22.5% with no speed limit (stylised, assumed parameters).
- How much of the time-optimal carry's edge survives a jerk-limited (S-curve) profile?Does rounding the trapezoid's corners (a jerk-limited S-curve) change the time-optimal carry's edge? An S-curve is never faster than the trapezoid and costs 0.0 to 2.0% (half-jerk) or 0.0 to 7.0% (full-jerk) at speed limits of 2 and 1 rad/s, but 1.4 to 33.7% with no speed limit (stylised, assumed parameters).
- At tight joint-speed limits, is the time-optimal carry's edge over a trapezoid real or an artefact of the ramp grid?Checks
robofab-scurveon a finer ramp grid: sampling a 0.2% ramp is needed or the trapezoid wrongly beats the time-optimal solver; with it the time-optimal edge at 2 and 1 rad/s is −0.3 to +0.9%, below the solver's own ~0.5% node-count error (stylised, negative on the old figure).
All 53 Robot manufacturing loops projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.