What do risk-averse verifiers report under proper scoring?
research/risk-averse-scoring
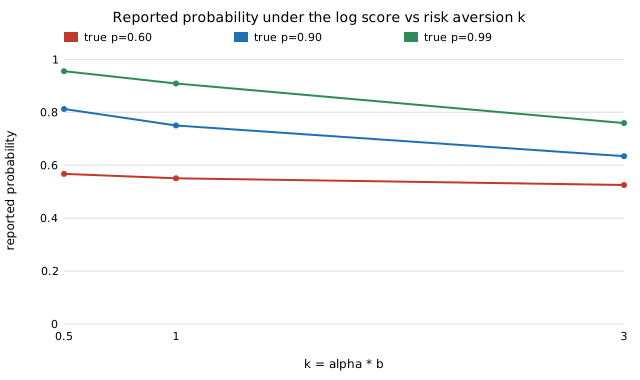
Risk-averse verifiers under proper scoring: log score reports exactly odds^(1/(1+αb)), Brier reports solve logit p = logit r + k(2r−1) and can be debiased exactly, a mean-k aggregation correction is worse than none, and a binarised lottery rule is truthful for any utility at a 2.6–27% certainty-equivalent cost.
What it found
Proper scoring rules are truthful only for risk-neutral agents. For a CARA verifier the log score yields reported odds exactly equal to true odds^(1/(1+k)), k = αb; the Brier score yields logit p = logit r + k(2r−1), which the principal can invert exactly. Summing reported logits under-extremises (log-loss 0.332 vs 0.214 at k=2); correcting with the mean k under heterogeneous verifiers is worse than not correcting; a log-score report needs true belief 0.964 to clear a 0.9 accept threshold at k=0.5. A binarised lottery rule is truthful for every increasing utility at a 2.6–27% certainty-equivalent cost. Stylised.
A figure from its own output
Paper, code and results
More in Proper scoring & elicitation
- What does a verifier's silence tell you?Selective reporting under proper scoring: abstention iff
|p−α| < √c(Brier), silence is evidence unless the anchor is a symmetric prior, ignoring it costs 30× the log-loss at n=12, and a stale anchor makes silence point at the wrong state. - How do you price the tail of benign drift?Jointly eliciting VaR and expected shortfall of benign drift with a scale-free Rockafellar–Uryasev score: ES alone is not elicitable, misreport cost is exactly
ln r + 1/r − 1, quantile-only tolerances leavea/(a−1)of the Pareto tail uncovered, and auditing tail reports breaks down at index ≤ 2. - Should you pay verifiers for their calibration?Paying verifiers for resolution, not calibration: raw Brier/log excess is exactly
E[(r-p)²]/E[KL(p‖r)], Brier is bounded but log is not, log-score selection reverses for overconfident high-resolution verifiers (a ≥ 2.49), and n-sample recalibration coststr(HI⁻¹)/2n(0.264/n). - Should a verifier's continuous drift report be scored by CRPS or log score?CRPS vs log score for continuous drift reports: exact Gaussian closed forms, overconfidence capped at
0.234σunder CRPS (unbounded under log), 1-Lipschitz outcome sensitivity, plug-in cost5σ/(8√π n), and finite score variance for tailsν>2vsν>4. - Can a verifier be paid for reporting drift variance?Eliciting drift variance from two independent re-executions:
D=(y1−y2)²/2unbiased withVar=σ⁴(κ+1)/2, exact Brier and scale-free misreport costs (1/λ+ln λ−1), detection needs≈2z²(κ+1)/(λ−1)²tasks, disjoint pairs 1.8× worse than the sample variance, heavy tails breakm^{−1/2}concentration. - What can be elicited from several independent draws of benign drift?Eliciting drift *variance* from pairs of independent draws: exact pair score (excess loss
(r−σ²)²), degree table (mean² 2, third moment 3, σ⁴ 4), audit cost((z_α+z_β)/ρ)²(κ+1)/2pairs, robust Gini score beats it for heavy tails, all-pairs pooling saves(κ+1)/(κ−1), correlated draws bias the target toσ²(1−ρ).
All 28 Proper scoring & elicitation projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.