Can a learned Markov chain over a person's webcam frames fool a detector?
research/mimic-webcam-markov
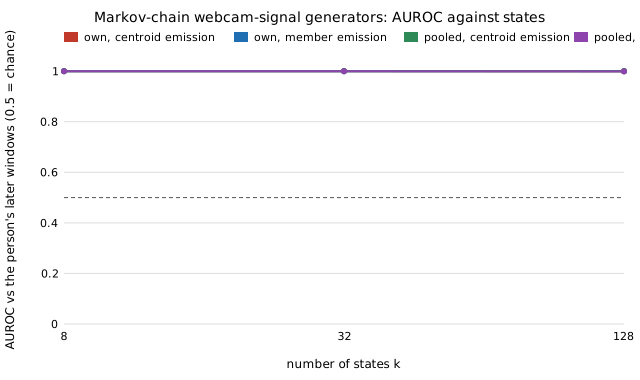
Can a Markov chain over a person's frames fool a detector? No: chains with 8, 32 or 128 states, fitted on one person or on everyone, emitting state centres or real frames, are caught at AUROC 1.000 (one cell 0.999), where stitching the same real frames in 50-frame blocks scored 0.57 to 0.65.
What it found
A first-order Markov chain over k-means states (k = 8, 32, 128) of DUX webcam-signal frames, fitted on one person's earlier windows or on the other 45 people's, emitting state centres or real frames, is scored against that person's later windows by a boosted-tree detector (3 seeds). Every cell is AUROC 1.000 except pooled 128-state member emission at 0.999, in the population and the profile-aware detector alike. Nearly every feature group alone separates them at 0.92 or more, so the chain gets none of the window-scale statistics right even when it emits real frames; 50-frame blocks of the same frames reached 0.57 to 0.65 in the predecessor project. A guess that chains lose between-window differences is only partly supported. Stylised: one form-filling context, first-order chains only.
A figure from its own output
Paper, code and results
More in Adversarial human imitation
- Does fitting a webcam-signal generator to one person fool a detector that has seen that person?Does fitting to one person help? Copying a person's own earlier windows is caught at AUROC 0.59 to 0.65 on their later windows; copying other people is 0.58 to 0.91, and 0.93 to 0.97 once the detector knows the person; a fitted parametric generator is caught at 1.000 either way.
- Does giving a Markov chain dwell times or a second-order memory let it fool a webcam-signal detector?Does giving a chain over a person's frames dwell times or second-order memory help? No: semi-Markov and second-order chains (8 or 32 states, own or pooled fit, centre or real-frame emission) are all caught at AUROC 0.999 to 1.000.
- Why is block-stitched real webcam signal still caught: the joins, or mixing people?Why is block-stitched real webcam signal still caught? With 50-frame blocks random stitching gives AUROC 0.887, one person's windows only 0.687, join-matched 0.796, both 0.588 (= whole-window replay 0.597); at 5 frames all are caught (8 seeds).
- How well do prompt-free detectors tell people from a plainly prompted LLM, and do they carry over to unseen kinds of text?How well do prompt-free detectors tell people from a plainly prompted LLM, and do they carry over to unseen kinds of text? Eight RAID families split by family: n-gram detector AUROC 0.93 and Binoculars-style 0.80 on held-out families, length at chance. Preliminary first step of track 11.
- Do the file sizes and line counts of this repository follow Benford’s law?Do this repository's file sizes follow Benford's law? Not as a whole (byte MAD 0.018, nonconforming) because templated files repeat the same size thousands of times; counting each distinct size once gives acceptable conformity (MAD 0.0068).
- Can prompt search alone move a frozen 0.5B imitator past a prompted 0.5B detector, and which proposer does it best at equal budget?Can prompt search alone move a frozen 0.5B imitator past a prompted 0.5B detector? A stylised first run of the imitation game, four proposers at equal budget on two families: the starting detector is below chance, proposers cannot be ranked at this size, and length is a major confound.
All 41 Adversarial human imitation projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.