How much bandwidth can a controller tuned in a twin with an instantaneous actuator really have?
research/lag-twin
A twin with an instantaneous actuator is stable at any gain; the real loop with lag τ is stable iff τ<kd/kp=2ζ/ωn, hunts at the twin's own ωn, decays no faster than 1/(3τ) for any gains, and the real-optimal bandwidth is ≈0.26–0.46 of the limit.
What it found
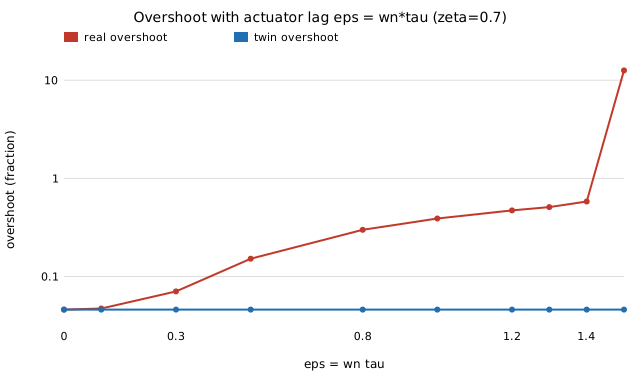
Unit mass under PD control with a first-order actuator lag τ the twin omits. The twin’s loop is stable for every gain; the real loop is stable iff τ<τ*=kd/kp=2ζ/ωn (Routh, agreeing with the roots in 168 of 168 cases), hunts at exactly the twin’s own ωn, and grows at ωn2/(2(1+4ζ2)) per unit excess lag (formula, numeric slope and simulation agree). “Faster is better” fails: at τ=0.05, ζ=0.7 the real decay rate peaks at 4.8 (ωn≈8) and is zero at ωn=28 where the twin promises 19.6; the poles sum to −1/τ, so no gains decay faster than 1/(3τ). Mild lag is nearly invisible in a step test (twin RMS error ≈0.04 ε). Companion to the slew, deadband and backlash twins. Stylised: linear, one lag, noiseless.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- How high a bandwidth does a rigid-body twin let you push when the real joint is flexible?A rigid-body twin certifies every PD bandwidth; with load-side sensing the real two-mass loop is unstable above
ε_c ≈ δ/ζof the flexible-mode frequency (exactly independent of mass ratio, unstable at any gain with no modal damping), step-response validation misses it, and the certified bandwidth inherits modal-damping error one-for-one. - Does a twin that models each axis alone certify gains that actuator coupling destabilises?A per-axis twin of a two-axis loop certifies gains that actuator coupling destabilises: stable-gain limit
2/(1+√p)not 2 (a 10% margin fails atc=1/9), twin-deadbeat rate is√|p|not 0, and a fitted diagonal gain1+cρdepends on log correlation while the full fit's variance grows as1/(1−ρ²). - A twin with an unlimited actuator says a PI step response ignores step size: what does the real loop with a command limit do?A twin with an unlimited actuator is exact for a PI step only while
kp·x0 ≤ U; beyond it the integrator winds up tox0²/(2U), overshoot rises from 21% to 97% and settling from 4.9 to 944, loadsd ≥ Uare never rejected, and the twin-tuned faster gains settle slower (clamping recovers most). - A fixed-step twin of a bouncing ball: how wrong are its restitution and time to rest, and does calibrating on the first bounce fix it?A fixed-step twin of a bouncing ball: the true rest time
(v1/g)(1+e)/(1−e)is hypersensitive toe(2/(1−e²)), the twin's apparent restitution and settling time are off by O(dt) with scheme-dependent sign (−20% to +4% at dt=10⁻², e=0.9), and calibratingeon the first bounce is not a reliable fix. - Does a twin fitted to the sensor-delay histogram certify gains that bursty delay makes unstable?A twin fitted to the sensor-delay histogram is blind to its persistence: i.i.d. jitter at the mean delay barely moves the mean-square gain limit (1.00 for {0,2}), but with the marginal fixed, lag-1 autocorrelation 0.9 cuts it to 0.67 (0.9 certified by the twin is unstable from ρ=0.435) and inflates variance 2.4×; almost-sure stability (≈1.84) hides it.
- Does a twin with no gravity certify PD gains that sag, or cannot hold a pose at all?A gravity-free twin certifies PD with zero error; the real pendulum sags to the root of kp(θ*−θ)=g sin θ (0.18 rad at kp=4, falling only as ~1/kp), cannot hold upright unless kp>g (basin 0.12 rad at 1.02g), and a 10%-off gravity feedforward leaves a sag linear in the error.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.