Does the hanger-fit width result survive when its assumed fabric constants are swept two orders of magnitude?
research/hanger-sweep
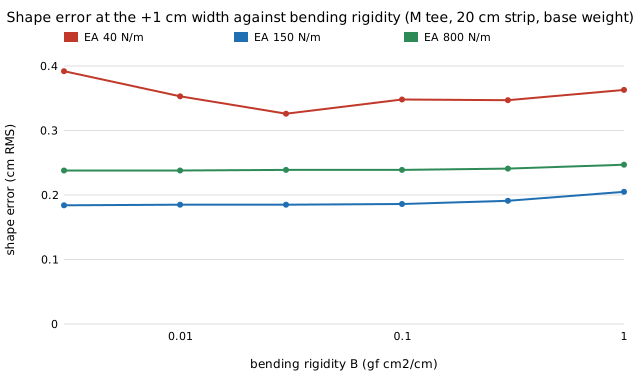
Does hanger-fit's "arm 1 cm wider than the half shoulder" survive 162 swept fabrics (bending rigidity 0.003–1, weight ×0.5–2, stretch 40–800 N/m, strip depth 10–30 cm)? Best offset is +1 cm in 151 and +2 cm in 11, all of them stretch 40 N/m; bending rigidity alone moves the best error under 10%. Constants swept, not sourced.
What it found
hanger-fit's drape uses round-number fabric constants. This sweep re-scores its width finding on a full factorial of 162 size M tees (bending rigidity 0.003–1 gf·cm2/cm, weight ×0.5–2, stretch stiffness 40–800 N/m, strip depth 10–30 cm) and one-at-a-time for the child and XXL tees. The best arm half width is the half shoulder + 1 cm in 151 of 162 and + 2 cm in 11, all with stretch stiffness 40 N/m and mostly double weight or a 10 cm strip (best error 0.9–1.7 cm against about 0.2 cm); child and XXL stay at + 1 cm throughout. Bending rigidity alone changes the best error by under 10% (median 0.23–0.25 cm over a 330-fold range). The only sourced input is a patent's range for knit cotton bending rigidity (0.002–0.050, from a search excerpt); stretch, weight and depth ranges are swept, not measured, and vary independently.
A figure from its own output
Paper, code and results
More in Laundry-hanging robots
- Does a second 3D cloth model, wrapped over the hanger arm, agree with the 2D hanger drape?Does a second 3D cloth model, wrapped over the arm, agree with the 2D hanger drape? On the cases both run, it picks the same best arm width (22.8 cm for a size M tee; error correlation 0.994) and adds the bend across the arm (119 deg/cm over a 0.5 cm arm, 34 over a 2 cm one), but disagrees for a heavy knit on a thin arm and is not grid-converged. Stylised.
- Should a laundry-hanging arm yield to the other arm's next pick only when the clash would be long? Gating lookahead by predicted overlap, paired on 1000 loadsShould an arm yield to the other arm's next pick only when the clash would be long? Gating by predicted overlap removes most of lookahead's loss and gains +0.7 to +1.35 garments an hour for pinching at 0.30 m (paired, 1000 loads). Stylised: inputs are placeholders.
- What hanger shape keeps a shirt in shape, and can one hanger fit every size?What hanger shape keeps a shirt in shape, and can one hanger fit every size for a laundry-hanging robot? In a 2D cloth-drape simulation the best single fixed hanger leaves garments 2.1 cm RMS from their worn shape (5.4 cm for a child's tee), one adjustable-width hanger set per garment 0.18 cm, and a rack of four widths under 1 cm for every size; thin wire ends fold the cloth at the tip. Stylised.
- Should a laundry robot hang a garment or fold it, and what can it sense to tell?Should a laundry robot hang a garment or fold it, and what can it sense to tell? A stretch-set and crease-set model on five fabric archetypes: woven shirts and linen are better hung, tees, fleece and heavy knits better folded; shoulder width, mass and stretch when lifted pick the better action for 89–91% of 600 simulated garments (always fold: 59%). The split depends mostly on the assumed crease model. Stylised, assumed fabric constants.
- How does a laundry robot get a hanger into a garment, and what does it cost the neck?How does a laundry robot get a hanger into a garment, and what does it cost the neck? A swept-section model of a rigid, telescoping or folding hanger passing a neck or hem loop: rigid hangers need 43–61 cm of loop, a tee's neck stretches up to 33% and a buttoned shirt collar cannot take them at all (shirts go in at the hem, 10 s against 6 s); a hanger that collapses to a 10 cm half width needs 31 cm. The round end
hanger-fitwants costs about 3 cm more. Stylised, assumed constants. - How many dryers can one laundry-hanging robot serve, and what limits it?How many dryers can one laundry-hanging robot serve, and what limits it? A discrete-event model of the whole cell (pick, sense, feeder, insertion, rail, fold table) fed by
hanger-insertandhanger-fold: with assumed times one arm clears a 25-item load in 8.9 min (about 5 dryers), a second arm adds 22% before the fold table binds, and the five hanger designs differ by at most 3%; pick and fold times dominate. Stylised, assumed station times.
All 25 Laundry-hanging robots projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.