How wrong is the stopping distance of a twin that models friction as purely viscous?
research/friction-twin
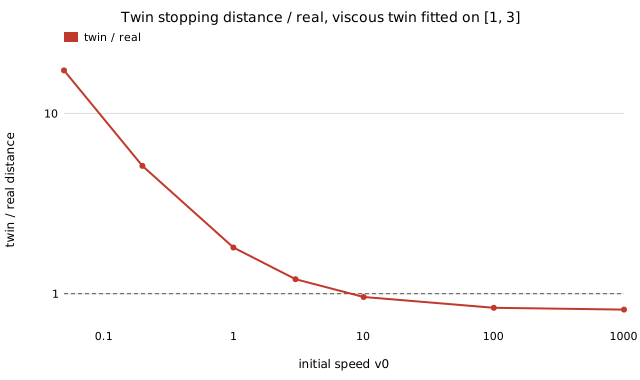
A viscous-only twin never stops (6.5–17.7 s to reach 1e-3…1e-9 vs 1.95 s real) and its fitted gain b + c·E[v]/E[v²] depends on the logged speed range; fitted on [1,3] it overestimates stopping distance ×1.8–17 below and underestimates above v*=7.3, no single viscous gain beats 0.87 worst error over [0.05,3], affine fit recovers exactly.
What it found
With Coulomb friction c the real coast-down stops in finite time with exact distance (m/b)[v0−(c/b)ln(1+b v0/c)] (RK4 agreement 9×10⁻⁹), while the viscous twin only decays exponentially (6.5 s to reach 10−3 vs 1.95 s real). The least-squares gain b+cE[v]/E[v2] depends on the logged speed range (1.23 on [1,3], 3.44 on [0.05,0.3]); fitted on [1,3] the twin overestimates stopping distance ×1.8 at v0=1 and ×17 at 0.05, is exact at 7.34 and underestimates above. Negative result: no single viscous gain does better than 0.87 worst relative error over [0.05,3], while an affine fit recovers (b,c) exactly. Stylised: one mass, noiseless logs.
A figure from its own output
Paper, code and results
More in Digital twins & sim-to-real
- Does a twin with correct sliding friction still miss stick-slip hunting from static friction?A twin with the right sliding friction says the PID loop converges, and with no stiction it does; a breakaway excess
Fs−Fcmakes the real loop stick-slip hunt at ≈0.5–0.9ΔF/kp(independent ofFc), and short runs can mistake a long stick for convergence. - How much bandwidth can a controller tuned in a twin with an instantaneous actuator really have?A twin with an instantaneous actuator is stable at any gain; the real loop with lag τ is stable iff τ<kd/kp=2ζ/ωn, hunts at the twin's own ωn, decays no faster than 1/(3τ) for any gains, and the real-optimal bandwidth is ≈0.26–0.46 of the limit.
- How high a bandwidth does a rigid-body twin let you push when the real joint is flexible?A rigid-body twin certifies every PD bandwidth; with load-side sensing the real two-mass loop is unstable above
ε_c ≈ δ/ζof the flexible-mode frequency (exactly independent of mass ratio, unstable at any gain with no modal damping), step-response validation misses it, and the certified bandwidth inherits modal-damping error one-for-one. - Does a twin that models each axis alone certify gains that actuator coupling destabilises?A per-axis twin of a two-axis loop certifies gains that actuator coupling destabilises: stable-gain limit
2/(1+√p)not 2 (a 10% margin fails atc=1/9), twin-deadbeat rate is√|p|not 0, and a fitted diagonal gain1+cρdepends on log correlation while the full fit's variance grows as1/(1−ρ²). - A twin with an unlimited actuator says a PI step response ignores step size: what does the real loop with a command limit do?A twin with an unlimited actuator is exact for a PI step only while
kp·x0 ≤ U; beyond it the integrator winds up tox0²/(2U), overshoot rises from 21% to 97% and settling from 4.9 to 944, loadsd ≥ Uare never rejected, and the twin-tuned faster gains settle slower (clamping recovers most). - A fixed-step twin of a bouncing ball: how wrong are its restitution and time to rest, and does calibrating on the first bounce fix it?A fixed-step twin of a bouncing ball: the true rest time
(v1/g)(1+e)/(1−e)is hypersensitive toe(2/(1−e²)), the twin's apparent restitution and settling time are off by O(dt) with scheme-dependent sign (−20% to +4% at dt=10⁻², e=0.9), and calibratingeon the first bounce is not a reliable fix.
All 164 Digital twins & sim-to-real projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.