What does it cost to route between models with conditional markets, and what does a stake do to the answer?
research/decision-markets
Conditional markets that route between models: inverse-propensity Brier is proper even when the router reads the report, exploration costs exactly 1+(K−1)e^{ω²/2τ²} in payment variance (probit: infinite for τ ≤ ω), and a stake gap distorts the reported gap by a closed-form fixed point with second-order harm.
What it found
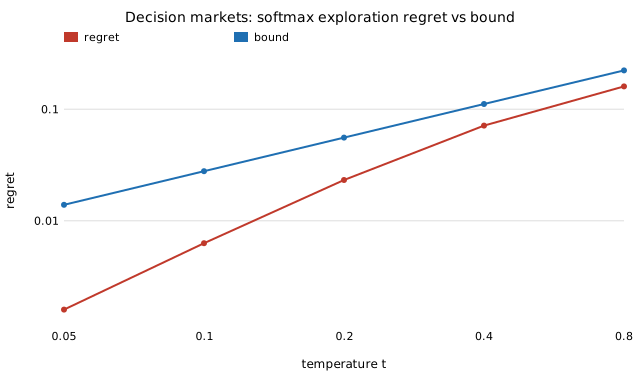
Markets that forecast each model’s loss if chosen only ever see the chosen arm. An inverse-propensity Brier payment is exactly proper even when the router reads the report (without the weight a trader shades its forecast, or hides), and its price is exact: E[1/π] = 1+(K−1)eω2/2τ2, so payment variance blows up as the router cools (a probit router has infinite variance for τ ≤ ω; Monte Carlo at τ=0.3 sees 29 against the exact 195). Exploration regret is at most 0.2785τ. Equal owner stakes cancel in the decision, a stake gap shifts the reported gap by a closed-form fixed point, and the loss it causes is second order, ∝(ΔB/k)2. Gaussian, one-shot, stylised.
A figure from its own output
Paper, code and results
More in Markets as routers
- What share of the mass should a new module get?Admitting new modules to a Hedge/LMSR router: regret certificates obey a Kraft identity
Σ e^{−c_i}=1, so uniform entry1/(n+1)is the unique minimax rule; prior-optimal sharesP_j/S_jcostH(P); the price of entry is exactlyln(1/π)/ηindependent of the quality gap. - How much liquidity does a payment system need, and what do netting and gridlock resolution save?Does bilateral or multilateral netting, or gridlock resolution, save a payment system liquidity? A simulator fitted to Bech and Soramäki's Danish and Finnish bounds (34.7% and 10.1% of gross value against the published 37.2% and 10.7% for DK) shows reciprocal flows are what make netting work, and resolution cuts delay by 24–46% in the Danish-shaped system but 34–62% in the Finnish-shaped one, where the paper found about 10%.
- How much longer is an electric delivery fleet's route plan once the battery and the chargers are counted, and does a charge-aware search recover it?Solomon RC208 (100 customers) with a battery: keeping the battery-blind routes and adding charging stops costs 28% more distance at 150 range units, a charge-aware search brings that to 5%; the battery is harmless above 200 units.
- Markets as routers: LMSR = Hedge, quadratic potential = sparsemaxCost-function markets as expert routers: LMSR = Hedge, quadratic potential = sparsemax; regret/loss bounds verified, continual-learning simulation.
- Wagering mechanisms as routers for modular, continually learning expertsSelf-financed wagering mechanisms as verifiable routers for modular, continually learning experts; shows plain WSWM locks in under recurring regimes and a fixed-share tax fixes it at the cost of subsidising free-riders.
- How much should a router extremize?Pooling calibrated experts with shared training data: Bayes-optimal extremization
a* = n/(1+(n−1)ρ)verified numerically, saturation atn_eff → 1/ρ, asymmetric robustness, and online learning of the exponent.
All 13 Markets as routers projects →
Other research topics
Proper scoring & elicitation28Effort & peer prediction9Verification games & slashing19Detection & tolerances14Markets as routers13Prediction-market design9Paying contributors8Decentralised training systems23Digital twins & sim-to-real164LLM chip design loops40Robot manufacturing loops53Ambient AI assistant46Self-replicating manufacturing34Simulation-first design64Engineered clothing45Task-specific AI accelerators40Algorithmic chip-design loops42Open-source purpose-built robots44The software-engineering loop43Adversarial human imitation41Open-source residential construction41Autonomous multi-angle capture34Sensing, imaging and 3D31Energy supply and dense energy storage39Robot societies among people31Agentic co-design of low-cost robots27Laundry-hanging robots25Machine learning on qualitative data23Robots on the building site27Civilizations & group psychology1History & human sciences1
Produced with AI assistance (Claude). Results are from the code in this repository and are simulated or stylised unless the abstract says otherwise; nothing here implies affiliation with or endorsement by any lab, researcher or company cited. MIT licensed.